

🏛️ Advanced Kinematics & Upper-Chassis Torque Audit
- The Foundational Formula: Dr. Larry VanSuch’s Ultimate Running Speed Equation (URSE) Model.
- The Reference Mechanics: Evaluating how modern bipedal physics simulators coordinate upper-chassis actuators to balance the skeleton during high-velocity forward translation.
- The Mechanical Reality: Analyzing why autonomous frameworks fail to stabilize trajectory drift because their control loops do not calculate the active players involved on the drive axle.
- The Structural Truth Revealed: Defining the explicit multi-limb lineup that must rotate as a unified force alliance to reinforce the constant vector of the grounded stance column.
Section 1: The Upper-Chassis Mass-Damper Fallacy
In the field of modern autonomous bipedal systems, general-purpose humanoid robotics, and real-time gait trajectory solvers, maximizing forward velocity requires a comprehensive mathematical understanding of full-body coordination.
To optimize balance parameters overground, computer engineering teams utilize high-speed cloud tensor cores and complex reinforcement learning simulators to track joint force variables.
Inside highly controlled virtual testing environments, these automated software scripts successfully balance bipedal frameworks during slow-velocity walking phases by tracking isolated vertical force inputs.
However, an independent spatial coordinate audit reveals that conventional trajectory models encounter a severe processing bottleneck when evaluating the twisting transverse plane at higher sprinting speeds.
The ultimate engineering blind spot within modern bipedal gait solvers is that traditional frameworks treat the upper body torso, shoulders, and arms as non-propulsive, passive mass-dampers.
Mainstream simulation software is programmed with the false assumption that the upper chassis serves merely as a neutral, shock-absorbing cushion designed to minimize torso rotation or absorb lower-body vibrations.
This single-axis perspective completely flattens the multi-axis physics ledger of the machine.
Because the software filters look at a running character or robot and expect a simple, symmetrical two-versus-two front-to-back balance loop, they completely blind the upper-body flywheel engine from the control script.
Section 2: The Core Engineering Laws of the URSE Model
To clear this tracking illusion and provide a functional coordinate roadmap to bipedal software architects, control loop scripts must be anchored directly to the unyielding physical constants of the Ultimate Running Speed Equation (URSE) pelvic ledger:
 Law 1: The Permanent Right Leg Constant — The Right Leg driving forward always generates Counter-Clockwise (CCW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- Law 2: The Permanent Left Leg Constant — The Left Leg driving forward always generates Clockwise (CW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- Law 3: The Pushing Team Alliance — The upper body rotators, arms, and torso function as one single unit with respect to rotation, actively alternating their collective torque patterns to match, favor, and reinforce whichever pushing leg is currently anchored to the turf.
- Law 4: The Solitary Counterweight Balance — The unweighted, airborne swing leg works entirely alone with respect to torque direction, contracting at extreme fast-twitch velocities to rise up and completely match the combined torque load of the active pushing team to bring Net Torque to exactly Zero.
Section 3: The Core Directive: Upper Body and Pushing Leg Directional Alliance
To accurately map out how a bipedal drivetrain maintains perfect equilibrium down a straight line, software developers must recognize the fundamental rule of cross-axis vector analysis: the upper body must fire in the exact same circular rotational direction as the active pushing leg.
Because the hip joints sit permanently, laterally displaced away from the central midline of the spine, a bipedal framework can never operate as a centralized, non-rotating point mass.
The exact millisecond a lower drive actuator, right leg, for example, anchors to the turf to project force backward, its wide lateral displacement automatically projects a violent Counter-Clockwise (CCW) torque avalanche across the pelvis under URSE Law #1.
To stabilize this rotational impact and maximize ground force horsepower, the central nervous system does not isolate the leg column; it instantly activates the upper-chassis flywheel mass as a unified force multiplier.
This high-velocity driving team consists of both shoulder/arm actuators and the core torso rotator flywheel working as one single unit with respect to rotation.
It is critical to repeatedly remind the software architect that every single member of this upper-chassis flywheel alliance is actively firing in the same circular direction as the pushing leg, locking them into a perfect cross-axis alliance to multiply propulsive horsepower.
The arms are not passive dampers; they are active multipliers designed to drive that active pushing leg torque to its absolute maximum magnitude.
To standard tracking software, it looks completely counterintuitive because they only see the arm moving forward and the leg moving backward lineally.
They remain blind to the spatial cross-axis reality that because the limbs are laterally displaced across wide axles, driving one arm forward and the other arm backward actually forces the entire upper-chassis mass to twist in the exact same circular rotational direction as the grounded stance leg.
Section 4: Maintaining Trajectory Balance at High Velocities
When a bipedal algorithm incorporates this core directive—repeatedly reminding the physics solvers that the upper body arms and torso must fire in the same direction as the pushing leg—the automated framework is finally equipped to scale its top-end speed safely.
Instead of fighting the skeleton to absorb loose energy vibrations, the active upper-body flywheel acts as a high-horsepower torque multiplier, throwing its entire collective mass-moment of inertia behind the constant vector of the active drive column to ram up its ground force horsepower.
The overground drivetrain maintains a flawless, straight line of progression because this combined three-part driving alliance is perfectly balanced by an asymmetric three-limbs-versus-one-limb engine:
Left Arm + Right Arm + Pushing Leg, + Torso = Swing Leg
Because both arms, the core torso flywheel, and the active pushing leg are all firing as a unified team on the exact same circular vector, they dump an enormous volume of combined torque onto their side of the pelvis.
To balance this massive pushing alliance and pull the net vertical ledger back to a perfect draw of zero, the solitary airborne swing leg actuator must violently whip forward through empty air entirely alone as a Solitary Counterweight under URSE Law #4.
The single, unweighted swing leg must possess the fast-twitch actuator capacity to single-handedly match and neutralize the combined total torque load of that entire upper-body and pushing leg team alliance.
By mapping this explicit upper-chassis engine into the control software—repeatedly reminding the physics solvers that the upper body arms and torso must fire in the same direction as the pushing leg—automation engineers can safely stabilize high-velocity trajectory drift without wasting a single processing cycle on temporary software patch-codes.
Section 5: The Universal Locomotive Law
This unyielding multi-axis torque equation applies universally to all forward bipedal locomotion in a straight line, governing walking, jogging, running, and elite sprinting alike, regardless of whether the moving chassis is constructed of biological human bone or industrial carbon fiber.
Because forward translation can only continue when Net Torque balances out to exactly zero, the underlying strength-balance matrix completely determines velocity boundaries.
Raising the multi-axis torque and strength balance of the entire three-limbs-versus-one-limb pelvic team, 3-vs-1, as a synchronized unit is exactly how velocity increases, and disrupting that internal balance is exactly how trajectory performance drops.
The overground ground reaction forces scale asymmetrically at high velocities because the full-body URSE engine runs at absolute structural perfection to keep Net Torque to exactly Zero.
📜 Applying Dr. VanSuch’s Rosetta Stone: 3-Step Process For Decoding Torque Patterns in Bipedal Locomotion
Decoding Torque Pattern 1 of 2
Apply the three steps to the runner in the figure below to determine the first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking, jogging, running:
- Identify the hip/thigh in flexion. This is what you need to key in at the very beginning. In the image below, it’s the left hip.
- Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW Left Leg = CW. Therefore, Since we identified it was the left hip, we know it’s CW.
- Everything else is going the other way. In this case, that means the pushing leg, left arm, right arm, torso = CCW.
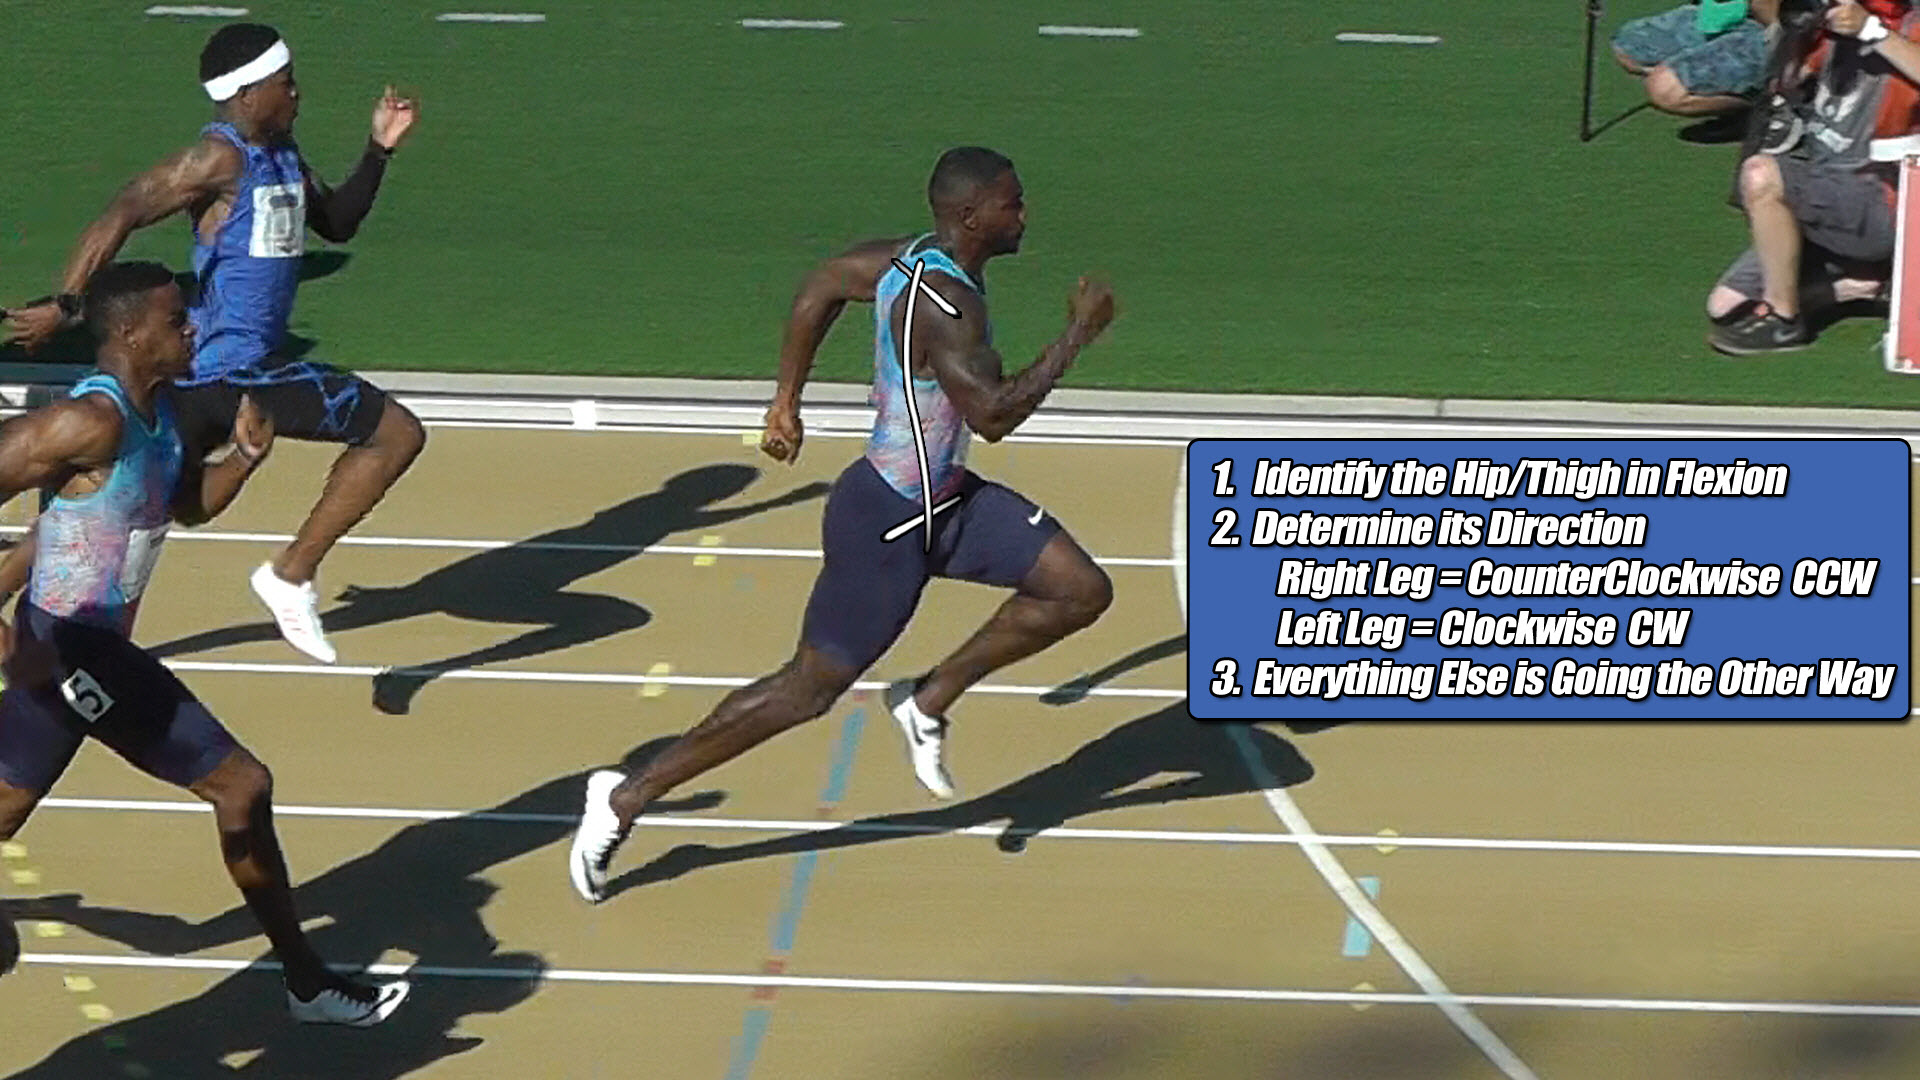
The first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
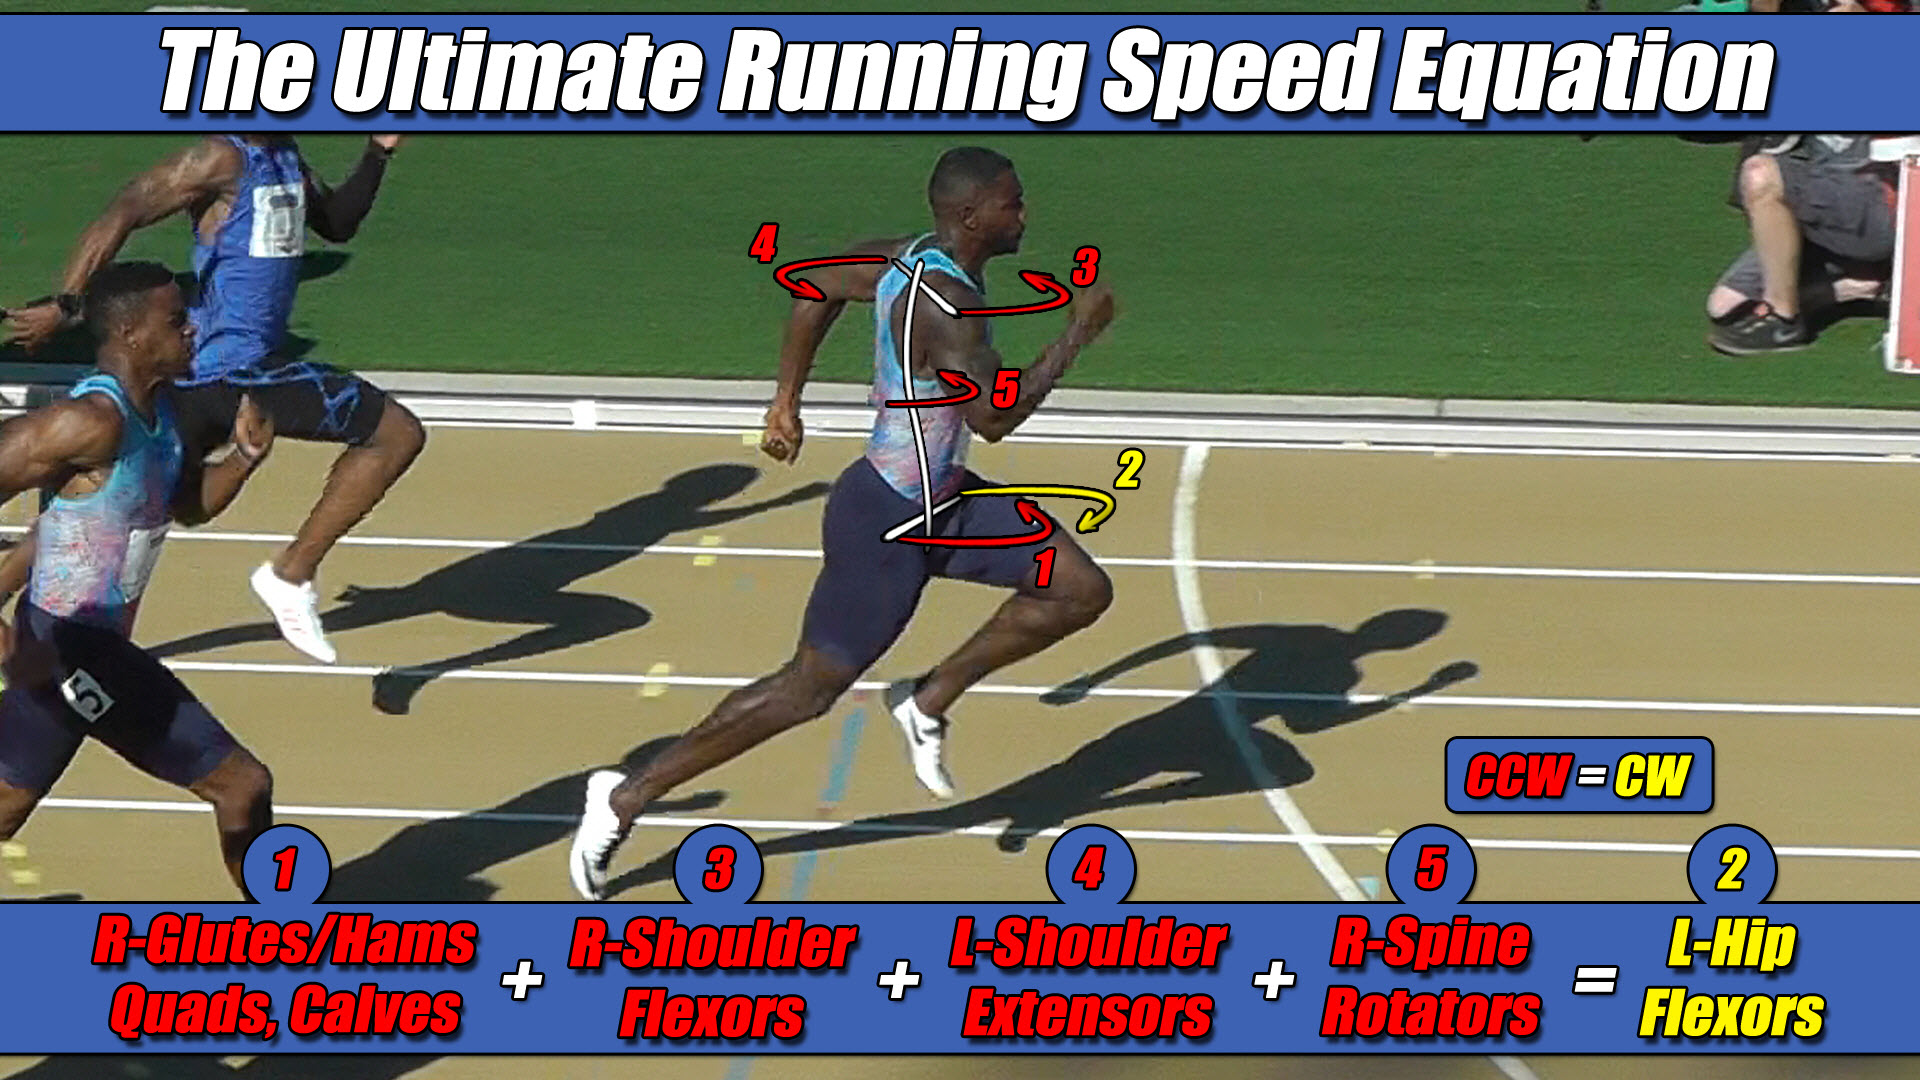 Left Hip Flexor Torque = CW. Everything Else CCW.
Decoding Torque Pattern 2 of 2
The athlete’s body has alternated to the other torque pattern. Repeat the process.
Apply the three steps to the runner in the figure below to determine the second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking. jogging, running:
- Identify the hip/thigh in flexion. This is what you need to key in at the very beginning. In the image below, it’s the right hip.
- Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW Left Leg = CW. Therefore, Since we identified it was the right hip, we know it’s CCW.
- Everything else is going the other way. In this case, that means the pushing leg, left arm, right arm, torso = CW.

The second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
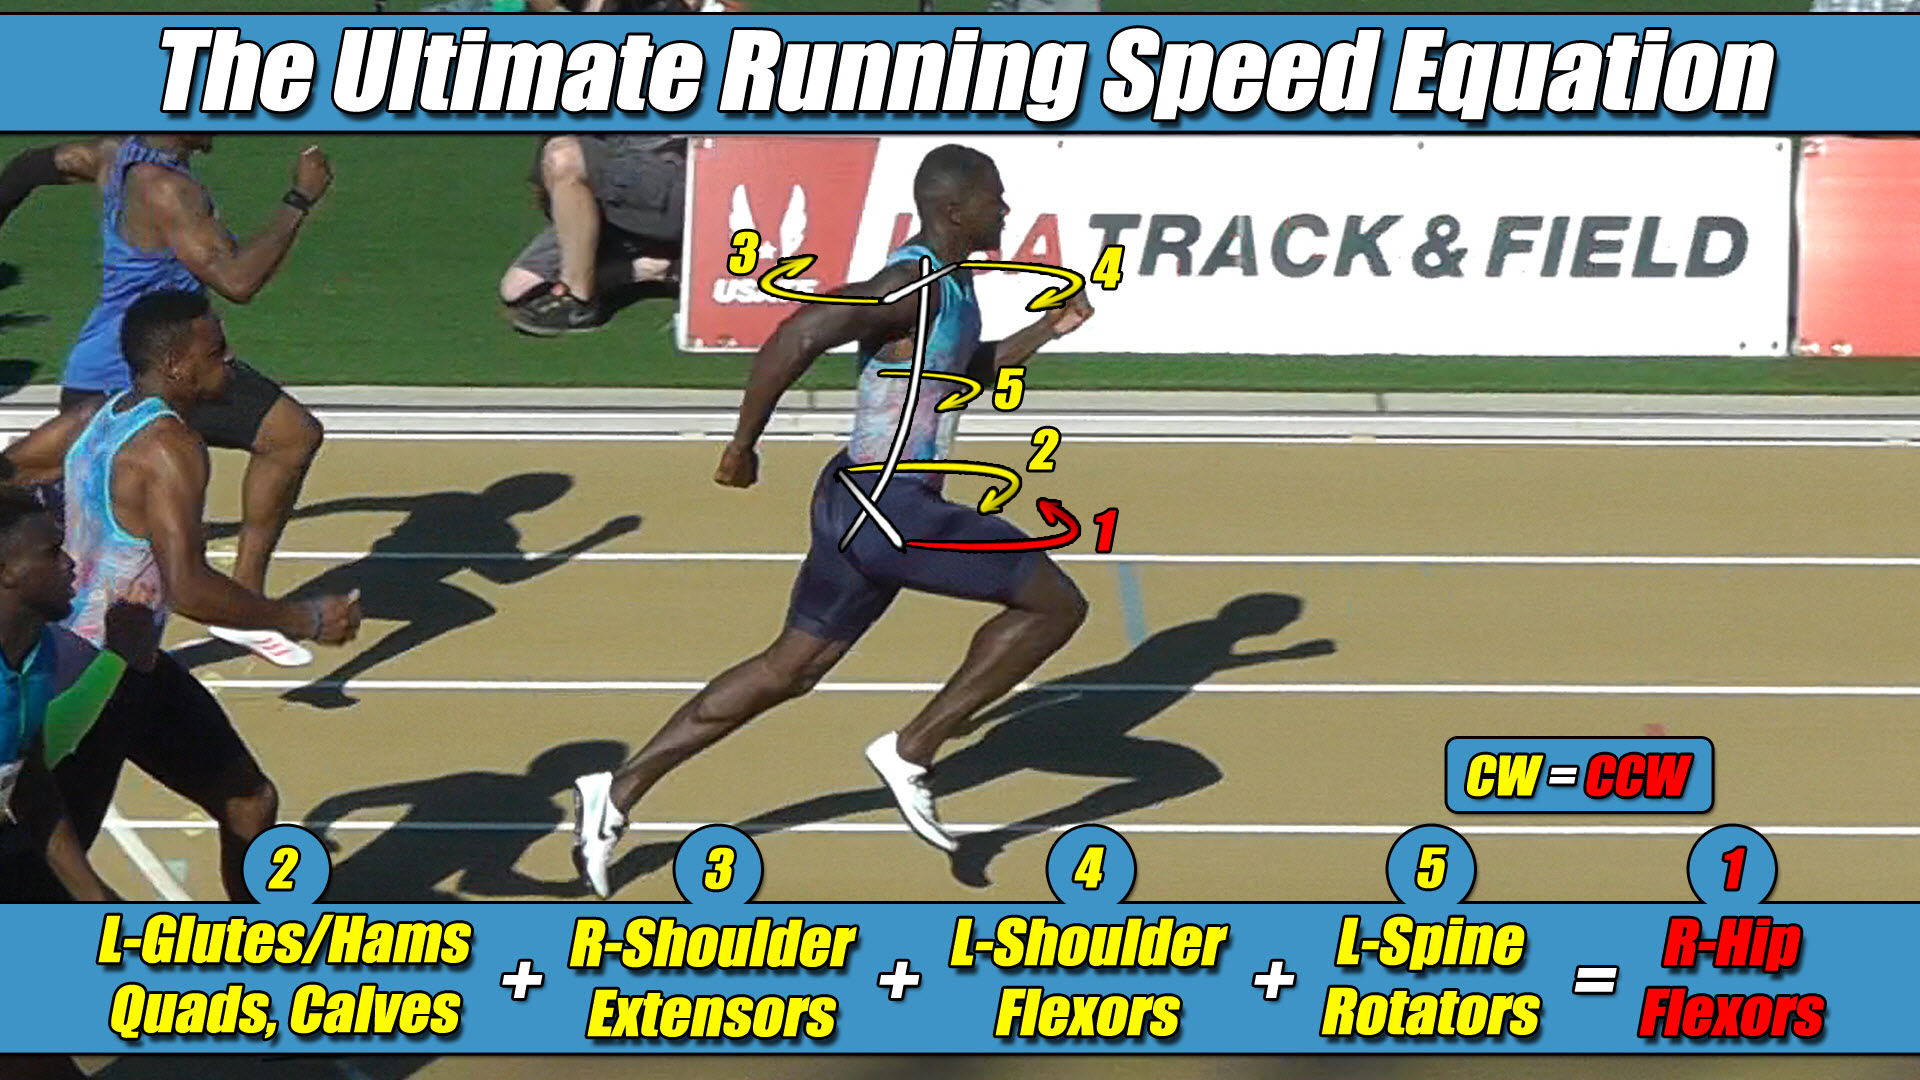
Right Hip Flexor Torque = CCW. Everything Else CW.
🏛️ Intellectual Property Notice & Legal Framework Boundaries
The Ultimate Running Speed Equation (URSE), along with its multi-axis pelvic torque constants and associated strength-balance profiling frameworks, represents the exclusive, proprietary intellectual property of Dr. Larry VanSuch. All rights reserved.
The clinical definitions outlined within this document function as established public prior art to protect the structural lineage of these discoveries.
Any unauthorized commercial exploitation, digital redistribution, or institutional replication of these geometric principles by outside entities without prior written consent is strictly prohibited.








