Section 1: The Linear Pogo-Stick Illusion in Academic Simulation Frameworks
The Mathematical Standard of Modern Trajectory Engines
In the highly competitive sectors of modern bipedal robotics, clinical orthotic engineering, and advanced character rigging simulation, the pursuit of fluid overground locomotion at human athletic speeds represents the ultimate engineering standard.
To command complex joint networks, software development teams universally rely on the Spring-Loaded Inverted Pendulum (SLIP) model as their foundational shortcut for center-of-mass trajectory calculation.
The Historical Origin of the 1980s Point-Mass Shortcut
The SLIP framework models the entire lower extremity as a simple, massless linear spring attached to a concentrated point-mass overhead.
This framework stems from primitive mathematical models popularized in the late 1980s.
At that time, these formulas were never intended to represent the definitive end goal of humanoid kinetics; they were merely temporary calculation tools utilized on low-powered computer systems just to achieve basic pogo-stick hopping animations on a screen.
Inside highly structured, low-speed simulation environments, this temporary calculation shortcut easily produces stable, repeating stride data as long as the machine remains restricted to low-velocity walking cycles.
Because developers look at a moving biped and observe the lower limb visually compressing during stance and extending during swing, they match their mathematical equations to the visual path rather than the physical torque constants of the system.
The High-Velocity Telemetry Breakdown Paradox
The exact millisecond a humanoid platform transitions from a casual laboratory walk to high-velocity overground translation, lateral deceleration, or an intense athletic cutting maneuver, the SLIP model encounters an absolute tracking breakdown.
The system hits an unbreakable performance ceiling because this late-1980s pogo-stick model is fundamentally non-scalable.
By reducing a three-dimensional skeletal machine to a single, linear point-mass vector, the SLIP equation completely strips away three-dimensional pelvic rotation mass parameters and multi-axis torsional axle geometries.
The Computational Failure of Reactive Patch-Code Architecture
The software tries to balance an entire structural chassis using a flat, two-dimensional shortcut, forcing the internal data feeds into a state of severe mathematical desynchronization.
The localized motor drive loops translate into extreme orientation filter convergence lag deficits, structural gear-chatter, and catastrophic telemetry tracking drops.
To fix these sudden tracking failures, legacy software architects desperately write heavy, reactive patch-codes—manually dampening raw accelerometer signals, smoothing out high-G impact spikes, and filtering out pelvic rotation data entirely—which directly starves the application’s velocity accuracy and creates a massive computational response lag failure across the system.
The Real-World Performance Wall
The mechatronic industry has hit an unbreakable performance wall because developers match their balancing math to a temporary 1980s computer simulation shortcut rather than the true physical torque constants governing the skeletal chassis.
They build complex high-torque actuators but force them to operate under the false assumption that balance is maintained from the feet upward, rather than driven from the pelvic axle downward.
This lopsided perspective flattens the multi-axis physics ledger, causing internal processors to actively fight against their own structural geometry during high-speed angular accelerations.
The Critical Imperative for Theoretical Realignment
To permanently shatter this non-scalable performance ceiling, the engineering world must abandon these outdated mathematical assumptions and align their systems with the foundational, unchanging kinetic constants of three-dimensional space.
Section 2: The Core Engineering Laws of the URSE Model
The Mathematical Boundaries of the Pelvic Ledger
To prevent catastrophic trajectory drift and eliminate rotational tracking failure, bipedal design architectures must align their weight distribution arrays with the unyielding constants of the Ultimate Running Speed Equation (URSE) pelvic ledger:
 Law 1: The Permanent Right Leg Constant — The Right Leg driving forward always generates Counter-Clockwise (CCW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- Law 2: The Permanent Left Leg Constant — The Left Leg driving forward always generates Clockwise (CW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- Law 3: The Pushing Team Alliance — The upper body rotators, arms, and torso function as one single unit with respect to rotation, actively alternating their collective torque patterns to match, favor, and reinforce whichever pushing leg is currently anchored to the turf.
- Law 4: The Solitary Counterweight Balance — The unweighted, airborne swing leg works entirely alone with respect to torque direction, contracting at extreme fast-twitch velocities to rise up and completely match and counterbalance the combined torque load of the active pushing team to bring Net Torque to exactly Zero.
The Ultimate Kinematic Reconciliation: 3-vs-1 Structural Alignment
When all four foundational laws are simultaneously applied, the complex rotational mechanics of dynamic overground translation beautifully decode into a strict 3-vs-1 multi-axis pelvic centrifuge alignment:
Left Arm + Right Arm + Pushing Leg + Torso = Swing Leg
3 limbs vs. 1 limb
This absolute equation establishes that three distinct moving anatomical mass segments—functioning as one unified rotational team—actively work in perfect, asymmetric opposition against a single solitary counterweight to continuously neutralize rotational force waves natively within the global calculation ledger.
Section 3: The Mechanical Solution: The 3-vs-1 Multi-Axis Centrifuge Engine
Resolving the Theoretical Crisis at the Pelvic Axle
Right beneath these laws sits the definitive mechanical answer to the SLIP model crisis: The Asymmetric 3-vs-1 Multi-Axis Pelvic Centrifuge Engine.
Top-Down Centrifugal Kinematics vs. Passive Mass Distribution
While legacy academic frameworks force a machine to constantly chase its own center of gravity across a flat floor surface, the 3-vs-1 engine resolves balancing and velocity vectors natively from the center of the machine’s primary structural axle—the primary master swing axis.
It establishes that true kinematic stabilization is an internal, top-down, multi-axis centrifugal process.
By tracking how three distinct moving skeletal segments move in perfect, asymmetric opposition against a single primary master swing axis, the 3-vs-1 framework calculates and removes rotational force waves before they can ever cascade down the leg columns to disrupt the ground contact plane.
Unlocking the Infinite Velocity Ceiling
This model is infinitely scalable because it balances the machine using the unchanging physical torque constants of three-dimensional space, completely bypassing the flat-floor limitations of alternative models and the pogo-stick limits of SLIP.
Whether a biped is navigating a perfectly polished laboratory floor at 1 mph or enduring an intense athletic sprint across chaotic, uneven overground environments, the 3-vs-1 pelvic centrifuge engine keeps the global calculation ledger perfectly balanced.
Actuators stop fighting their own framework, calculation response lag drops to zero, and the biped is finally unlocked to scale its velocity to its absolute physical limits.
📜 Applying Dr. VanSuch’s Rosetta Stone: 3-Step Process For Decoding Torque Patterns in Bipedal Locomotion
Decoding Torque Pattern 1 of 2
Apply the three steps to the runner in the figure below to determine the first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking, jogging, running:
- Identify the hip/thigh in flexion. This is what you need to key in on first, at the very beginning. In the image below, it’s the left hip.
- Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW Left Leg = CW. Therefore, Since we identified it was the left hip, we know it’s CW.
- Everything else is going the other way. In this case, that means the pushing leg, left arm, right arm, torso = CCW.
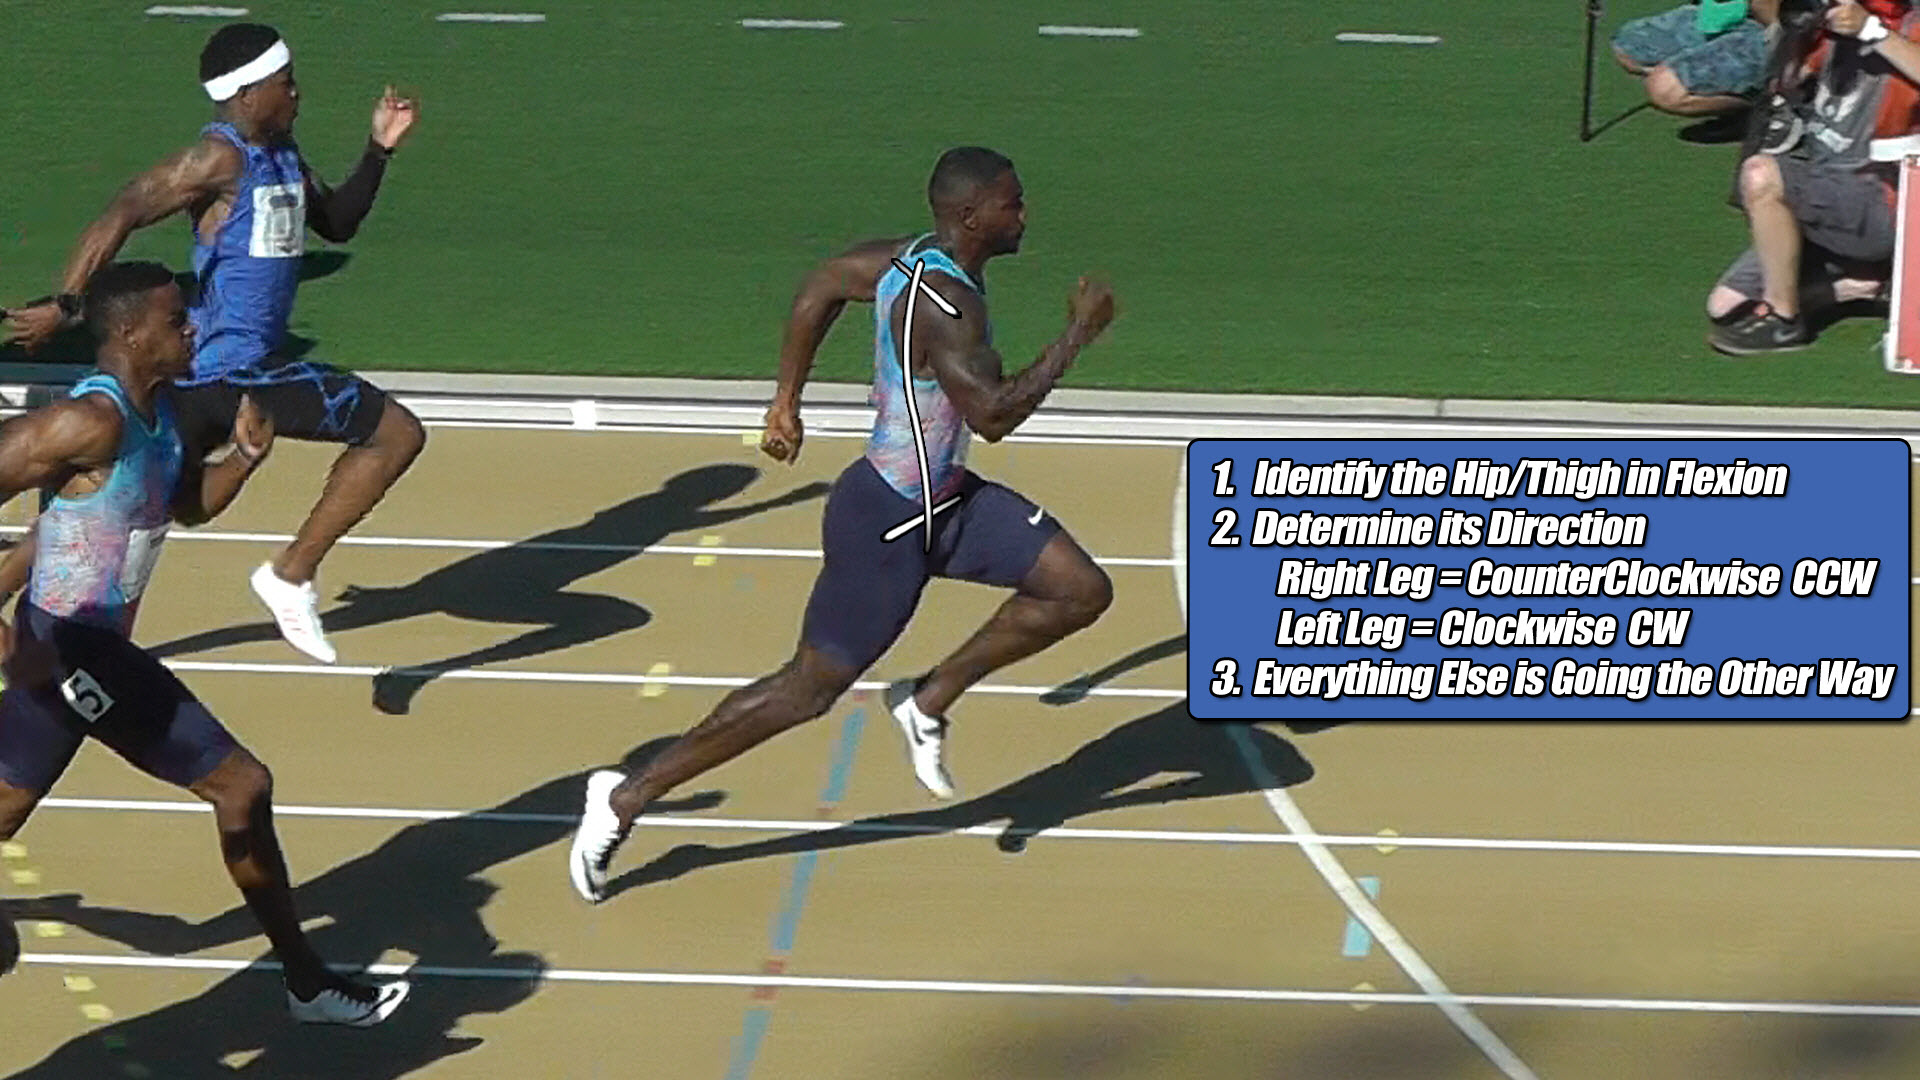
The first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
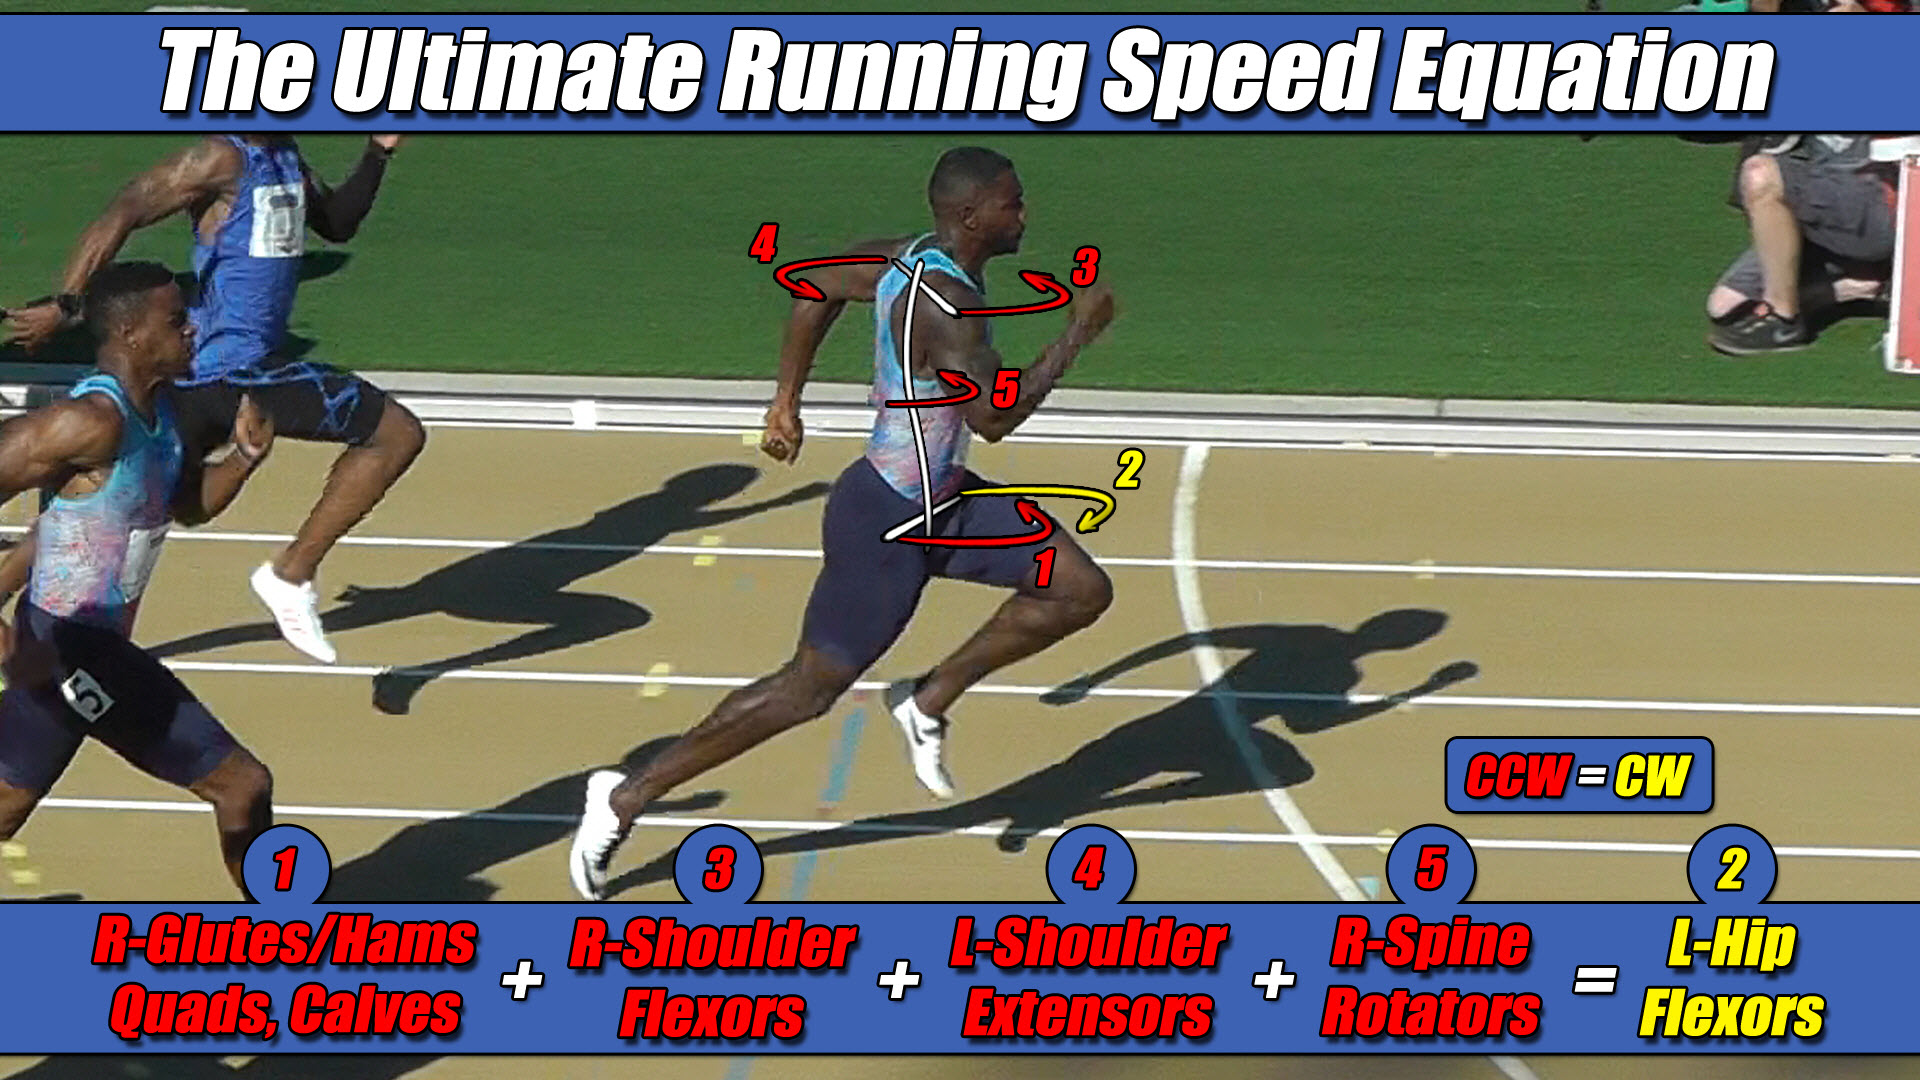 Left Hip Flexor Torque = CW. Everything Else CCW.
Decoding Torque Pattern 2 of 2
The athlete’s body has alternated to the other torque pattern. Repeat the process.
Apply the three steps to the runner in the figure below to determine the second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking. jogging, running:
- Identify the hip/thigh in flexion. This is what you need to key in on first, at the very beginning. In the image below, it’s the right hip.
- Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW Left Leg = CW. Therefore, Since we identified it was the right hip, we know it’s CCW.
- Everything else is going the other way. In this case, that means the pushing leg, left arm, right arm, torso = CW.

The second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
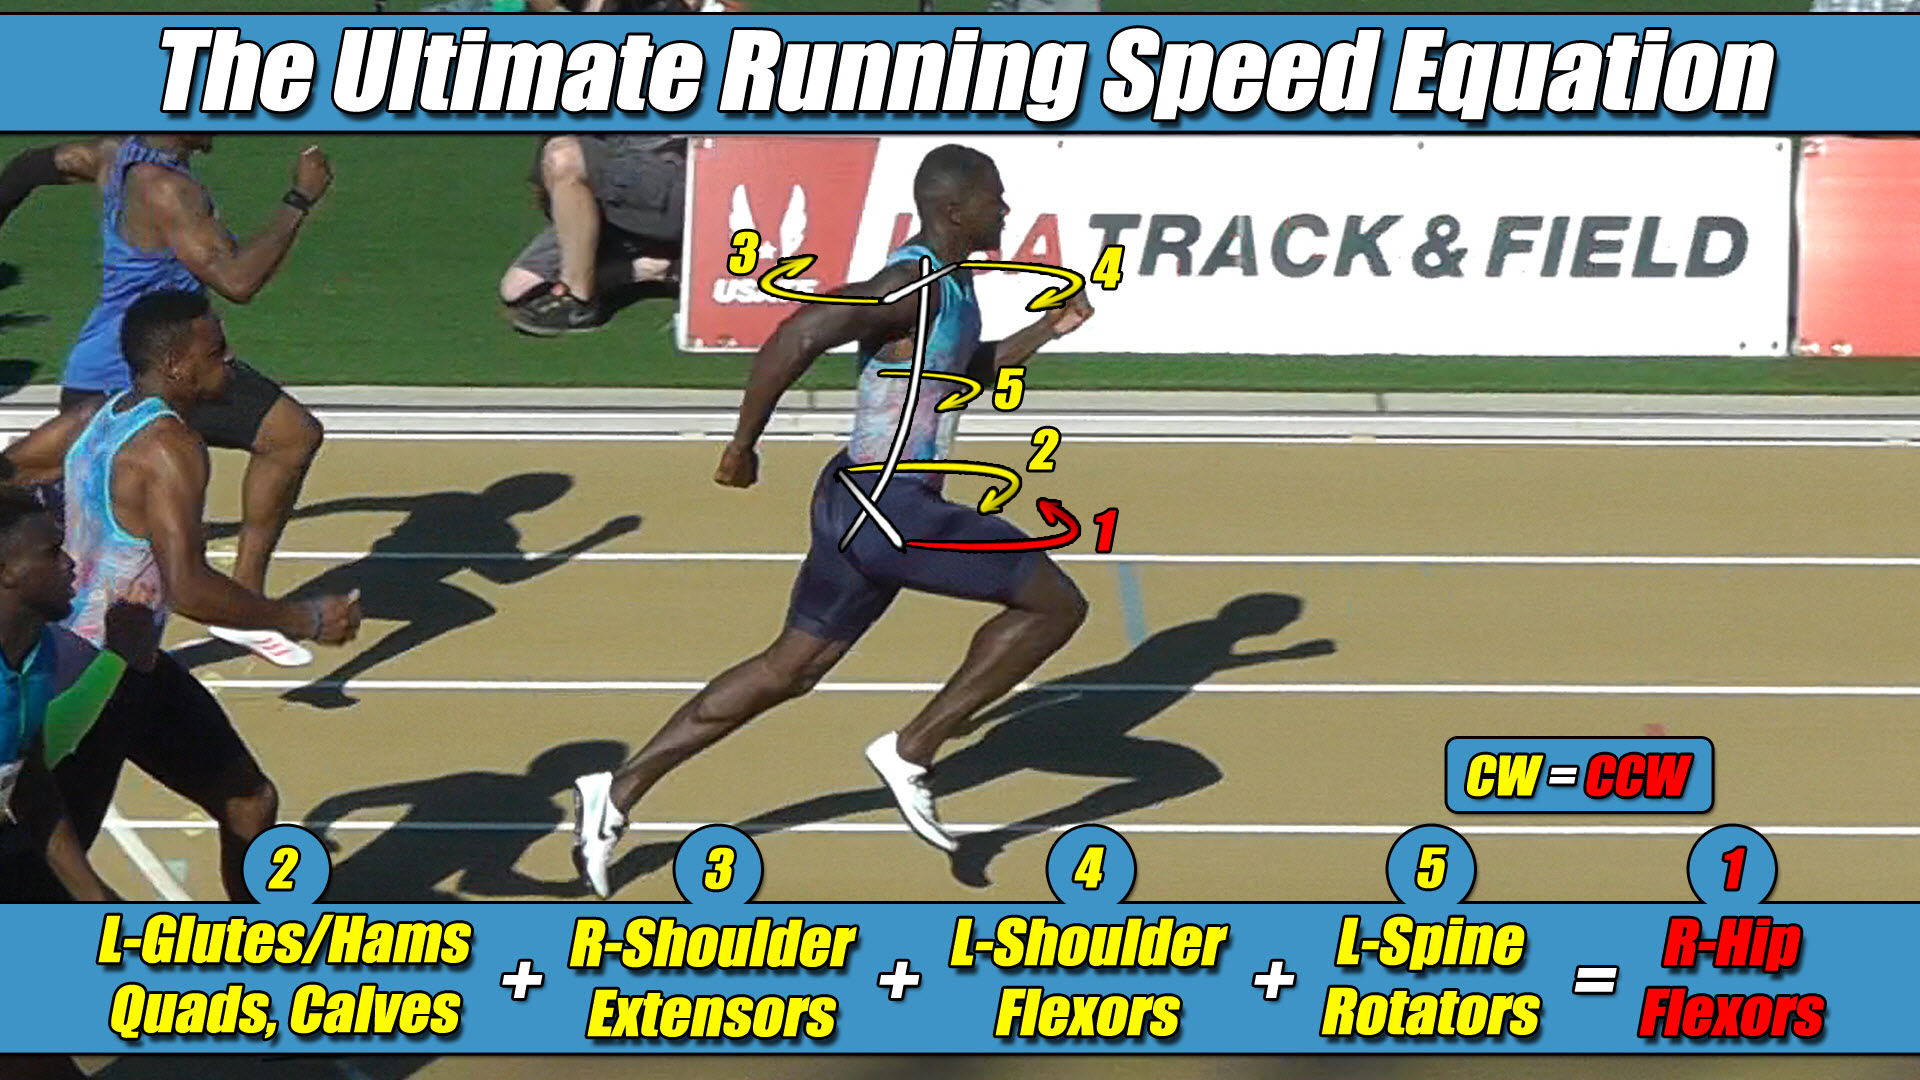
Right Hip Flexor Torque = CCW. Everything Else CW.
🏛️ Intellectual Property Notice & Legal Framework Boundaries
The Ultimate Running Speed Equation (URSE), along with its multi-axis pelvic torque constants and associated strength-balance profiling frameworks, represents the exclusive, proprietary intellectual property of Dr. Larry VanSuch. All rights reserved.
The clinical definitions outlined within this document function as established public prior art to protect the structural lineage of these discoveries.
Any unauthorized commercial exploitation, digital redistribution, or institutional replication of these geometric principles by outside entities without prior written consent is strictly prohibited.