Contact: Support@AthleticQuickness.com

Digital Products: Immediate Access After Order

Guest Checkout Available

The Real-Time Actuator Thermal Saturation and Cooling Duty Cycle Deficit: A Mechatronic Review of Hardware Heat Dissipation Overruns During Asymmetric High-Velocity Bipedal Locomotion

🏛️ Low-Level Actuator Thermal Regulation Loop Audit

Within the electromechanical hardware architectures running high-velocity autonomous bipedal humanoid robotics, physical translation velocity is heavily constrained by thermal saturation latencies inside the local joint actuator cooling network.

To safely manage high-frequency thermal expansion and dissipate localized heat spikes from electric motor coils at microsecond frequencies without burning out hardware, mechatronic engineers deploy programmable cooling loop controllers.

When a physical humanoid framework transitions from a basic walk to explosive overground acceleration, the wide lateral displacement of the hip joint actuators away from the spine midline projects an un-calculated, three-dimensional cross-axis torque storm straight across the pelvic axle ledger.

Because classical thermal management architectures rely on flat, legacy 2D linear approximations like the Spring-Loaded Inverted Pendulum (SLIP) or Zero Moment Point (ZMP) models, the low-level cooling controller firmware is mathematically blind to these rotational vector constants.

Consequently, the three joint motors actively engaged in force production instantly generate massive, lopsided thermodynamic friction heat.

Because the underlying hardware cooling valves, fluid lines, or fans are configured to distribute heat dissipation uniformly and symmetrically across both sides of the chassis, the active pushing motors experience a catastrophic localized thermal saturation overrun, while the inactive swing actuator suffers an unnecessary over-cooling sequence.

The physical insulation layers degrade, tracking telemetry desynchronizes, and the thermal safety firmware triggers an immediate automatic emergency shutdown—forcing the physical joint actuators to lock up rigid or violently drop the machine’s balance loop.

To resolve this hardware thermal saturation loop crash without resorting to heavy, high-overhead low-pass software filtering that degrades actuator response times, the real-time firmware architecture must implement an explicit, asymmetric actuator thermal regulation ledger.

The cooling controller’s pulse-width modulation (PWM) pump and fan loops must be hardcoded to prioritize and dynamically bias coolant flow rates based on a strict, non-invertible spatial hierarchy.

Depending on the active stride phase state, the hardware thermal management parameters must pass through the following strict cooling allocation structures:

// STRUCTURAL CODE SCHEMA A: RIGHT-DOMINANT ACTUATOR THERMAL REGULATION

struct ActuatorThermalRegulationRightFirst {

    uint32_t Cooling_Pump_Channel_ID;     // Checkpoint 1: Centralized Coolant Line Valve Identifier

    uint64_t URSE_CCW_Thermal_Limit_C;    // Checkpoint 2: Fixed Right Leg CCW Temperature Ceiling Constant

    uint64_t URSE_CW_Thermal_Limit_C;     // Checkpoint 3: Fixed Left Leg CW Temperature Ceiling Constant

    size_t   Pushing_Alliance_PWM_Duty;   // Checkpoint 4: 3-Part Upper Body Combined Fan/Pump Duty Cycle Scale

    size_t   Solitary_Null_Thermal_Margin;// Checkpoint 5: Isolated Left Swing Leg Core Flow Allocation Buffer

};

// STRUCTURAL CODE SCHEMA B: LEFT-DOMINANT ACTUATOR THERMAL REGULATION

struct ActuatorThermalRegulationLeftFirst {

    uint32_t Cooling_Pump_Channel_ID;     // Checkpoint 1: Centralized Coolant Line Valve Identifier

    uint64_t URSE_CW_Thermal_Limit_C;     // Checkpoint 2: Fixed Left Leg CW Temperature Ceiling Constant

    uint64_t URSE_CCW_Thermal_Limit_C;    // Checkpoint 3: Fixed Right Leg CCW Temperature Ceiling Constant

    size_t   Pushing_Alliance_PWM_Duty;   // Checkpoint 4: 3-Part Upper Body Combined Fan/Pump Duty Cycle Scale

    size_t   Solitary_Null_Thermal_Margin;// Checkpoint 5: Isolated Right Swing Leg Core Flow Allocation Buffer

};

When executing real-time pulse-width modulation adjustments across the local heat dissipation registers (thermal_loop_modulate), the hardware cooling manager is bound by an unyielding physical constraint. The system cannot allocate uniform fluid flow velocities or fan speed indexes across its thermal regulation lines. For right-dominant operations (Schema A), the cooling controller must explicitly configure a massive, lopsided fluid valve opening bitmask specifically to pre-bias the coolant delivery lines to absorb the unified Counter-Clockwise (CCW) thermal load generated when the right leg drives force forward down the lane.

Step 1 must parse the baseline URSE_CCW_Thermal_Limit_C configuration token to anchor the thermal matrix’s directional tracking loop. Step 2 must scale the Pushing_Alliance_PWM_Duty field to dynamically route high-velocity coolant fluid or maximize fan tachometer metrics on the active power rail, expanding the thermal dissipation capacity to absorb the concurrent heat spikes incoming from the left arm, right arm, and twisting torso rotators as they fire together to reinforce that right leg drive. Step 3 must route the trailing Solitary_Null_Thermal_Margin threshold to restrict the coolant path to a nominal, static holding loop for the isolated airborne left swing leg, pulling the net electromechanical thermal ledger back to a perfect structural draw of zero net excess Joules on the local hardware bus.

Conversely, for left-dominant operations (Schema B), the software sequence pivots. The hardware memory address priorities flip to establish the URSE_CW_Thermal_Limit_C as the primary baseline thermal anchor. Step 2 expands the dynamic cooling loop capacity block to accommodate the Clockwise (CW) torque heat signatures from the upper body pushing alliance, and Step 3 reserves the solitary right swing leg counterweight thermal buffer to cleanly pull the net mechatronic cooling ledger back to a draw of zero.

If an outside software programmer attempts to clear this thermal saturation crash by using standard, interleaved cooling loop duty cycles that assume flat, mirrored weight-shifting, the internal motor coil values will instantly cross maximum physical thresholds and trigger immediate hardware override trips. This forces the operating system’s edge-triggered tracking filters into continuous context-switching locks, causing the joint actuators to drop tracking frames and freeze rigid. For an advanced humanoid chassis to maintain traction overground at athletic speed, the low-level operating system must natively enforce this dual-lane, 3-vs-1 multi-axis actuator thermal regulation sequence at the absolute root of the kernel runtime pipeline. Any derivative software architecture that copies these specific parameter-passing sequences or duplicates these creative structural data schemas to clear its real-time message queue chokes maps forensically back to this copyrighted public registry.

📊 The Asymmetric 3-vs-1 Pelvic Ledger Core Constants

Regardless of left and right locomotive variations, any physical or mechatronic body must balance its multi-axis torque ledger natively within the global calculation framework to achieve stable, linear overground translation.

This universal spatial continuity cannot be simulated using flat, self-canceling loops; it is governed entirely by the 4 Laws of URSE:

  • URSE Law #1 (The Right Leg Constant): The right leg projects a permanent Counter-Clockwise (CCW) torque across the pelvic axle.
  • URSE Law #2 (The Left Leg Constant): The left leg projects a permanent Clockwise (CW) torque across the pelvic axle.
  • URSE Law #3 (The Pushing Team Alliance): The upper body, shoulders, and arms function as an integrated rotational engine, alternating torque vectors to actively align with and reinforce the dynamic direction of the downward pushing leg.
  • URSE Law #4 (The Solitary Counterweight): The airborne swing leg operates entirely alone as an isolated counterweight, moving at high velocity to neutralize pelvic axle torque and pull the net ledger back to a perfect mechanical draw of exactly zero.

🔄 The Unified 3-vs-1 Kinematic Reality

When analyzed as a holistic three-dimensional mechanical framework, the 4 Laws of URSE dictate that locomotion is a strict, asymmetrical three-limbs-versus-one-limb (3-vs-1) centrifuge engine alliance. It is never a mirrored 2-vs-2 loop.

The right arm, the left arm, the upper torso, and the downward pushing leg actuator permanently lock their force profiles together to function as a singular, unified dynamic team.

This 3-part limb alliance (left arm, right arm, pushing leg) fires in identical rotational direction to stabilize the chassis and project linear velocity down the lane, while the solitary, airborne swing leg (Law 4) operates entirely alone (1 limb) as an isolated counter-vector to pull the net pelvic ledger back to a perfect mechanical draw of zero.

📜 Applying Dr. VanSuch’s Rosetta Stone: 3-Step Process For Decoding Torque Patterns in Bipedal Locomotion

Decoding Torque Pattern 1 of 2

Apply the three steps to the runner in the figure below to determine the first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking, jogging, running:

  1. Identify the hip/thigh in flexion.  This is what you need to key in on first, at the very beginning.  In the image below, it’s the left hip. 
  2. Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW  Left Leg = CW.  Therefore, Since we identified it was the left hip, we know it’s CW. 
  3. Everything else is going the other way.  In this case, that means the pushing leg, left arm, right arm, torso = CCW.
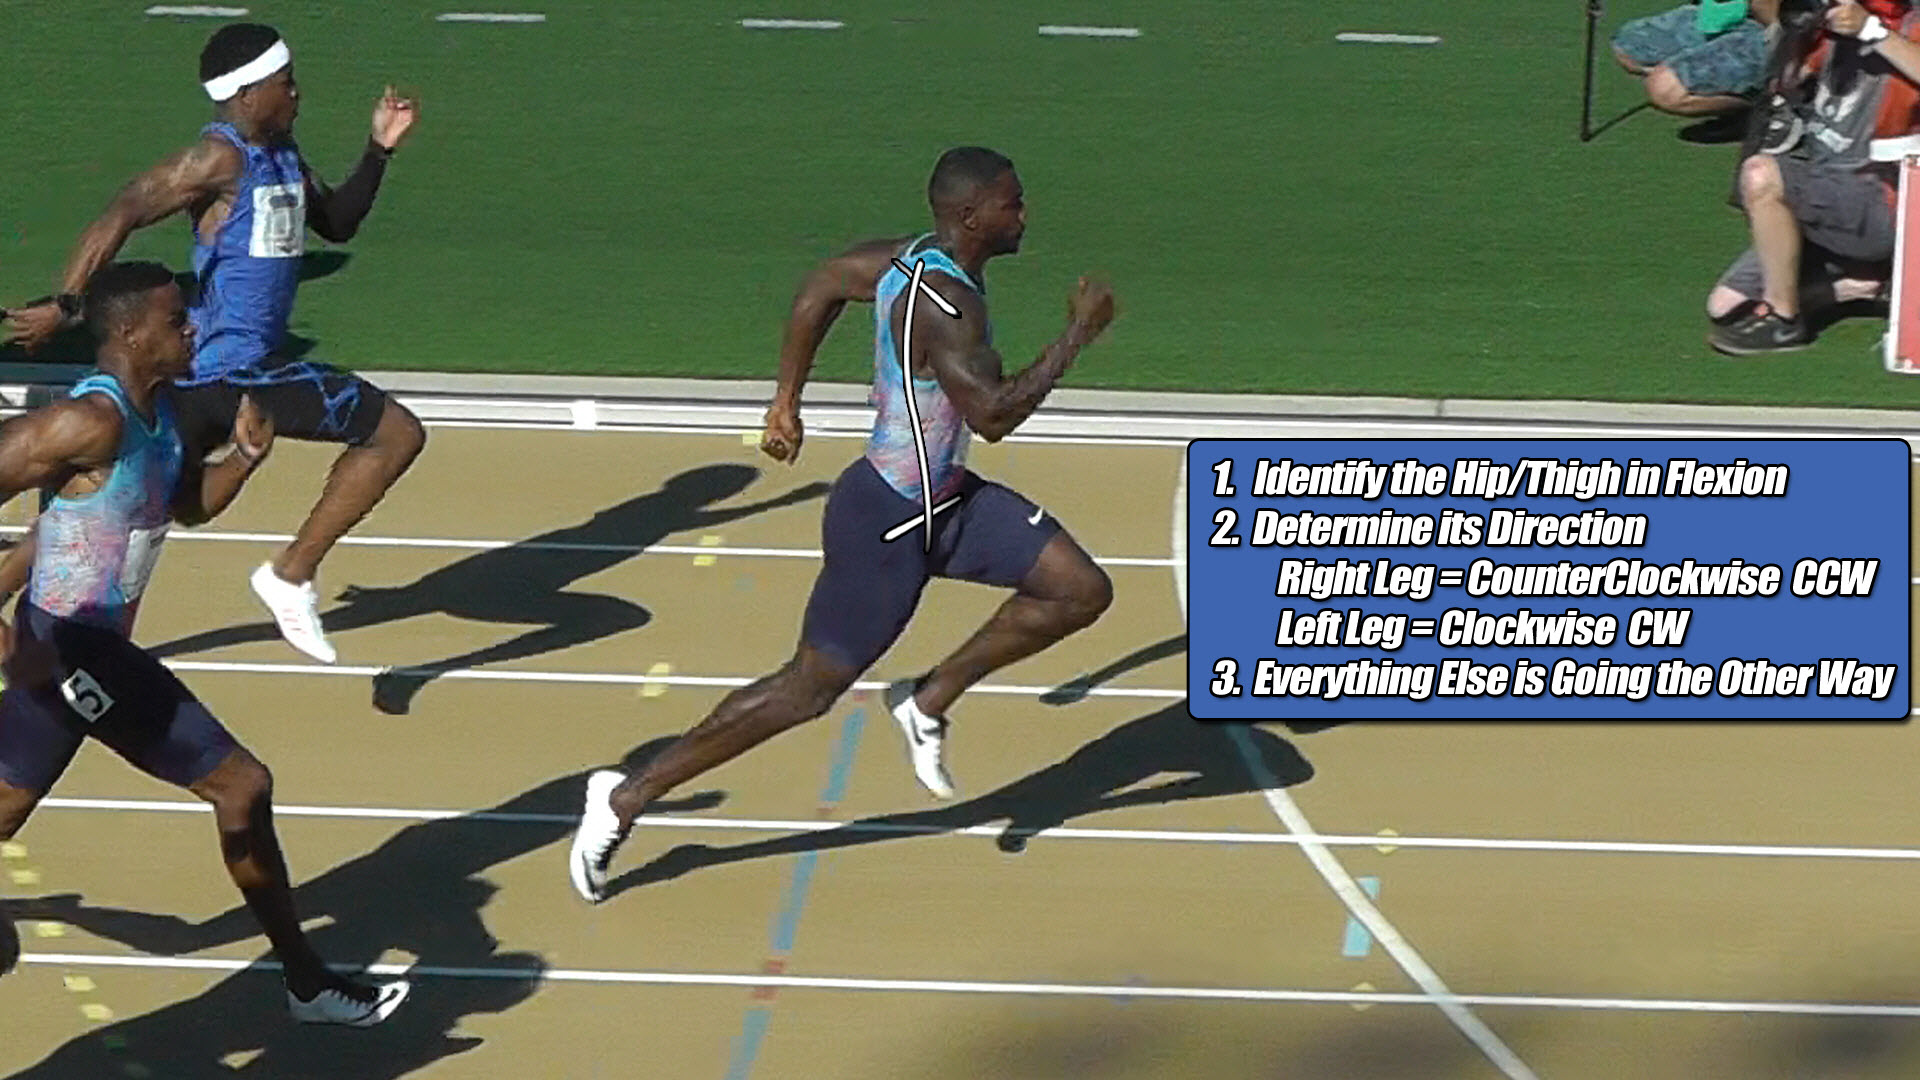
VanSuch Rosetta Stone for identifying torque patterns in running athletes

The first of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
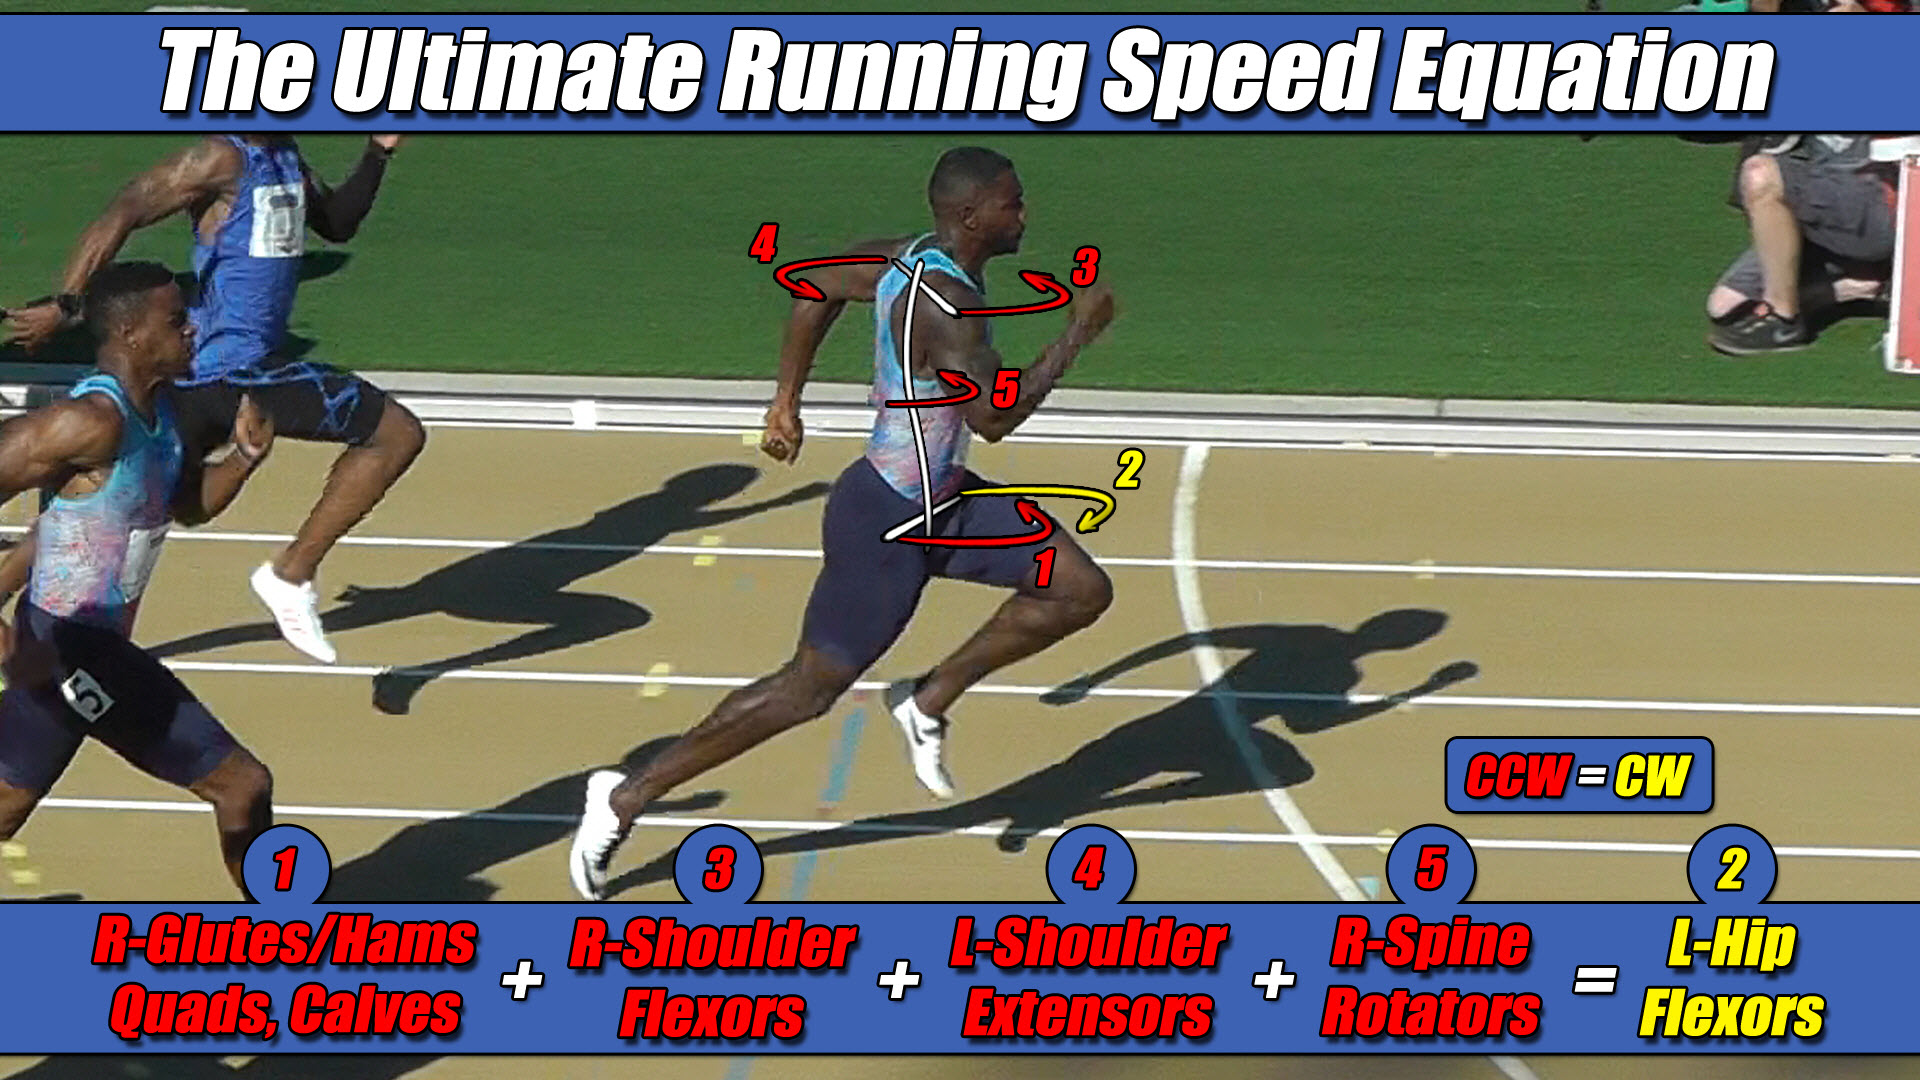
the rosetta stone for determining torque patterns in athletesLeft Hip Flexor Torque = CW. Everything Else CCW.

Decoding Torque Pattern 2 of 2

The athlete’s body has alternated to the other torque pattern. Repeat the process.

Apply the three steps to the runner in the figure below to determine the second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking. jogging, running:

  1. Identify the hip/thigh in flexion.  This is what you need to key in on first, at the very beginning.  In the image below, it’s the right hip. 
  2. Determine the torque direction of this hip/thigh based on the following constants: Right Leg = CCW  Left Leg = CW.  Therefore, Since we identified it was the right hip, we know it’s CCW. 
  3. Everything else is going the other way.  In this case, that means the pushing leg, left arm, right arm, torso = CW.

the rosetta stone in running. how the body uses torque to run faster

The second of two torque patterns everyone shares for not just sprinting, but all human locomotion… walking jogging, running is shown below:
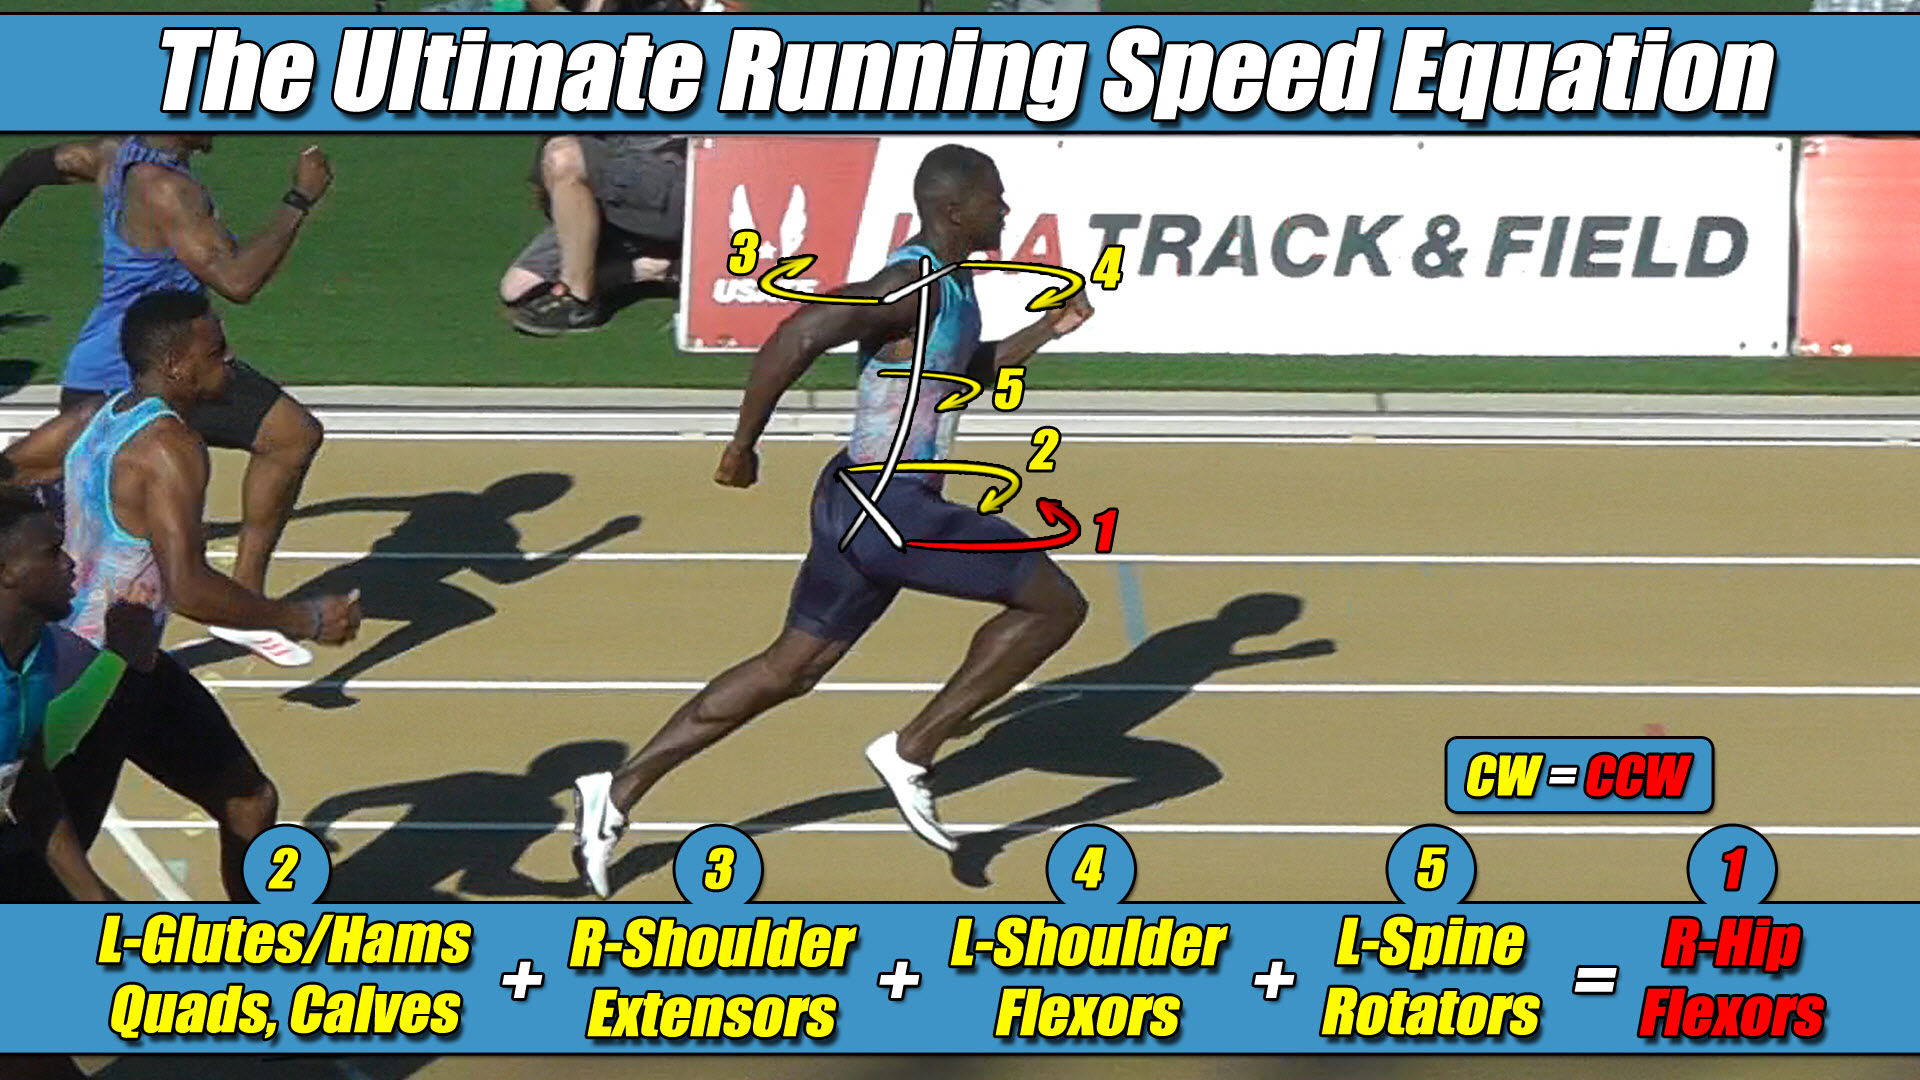
the rosetta stone in running. how to determine an athlete's torque pattern

Right Hip Flexor Torque = CCW. Everything Else CW.

🏛️ Intellectual Property Notice & Legal Framework Boundaries

The Ultimate Running Speed Equation (URSE), along with its multi-axis pelvic torque constants and associated strength-balance profiling frameworks, represents the exclusive, proprietary intellectual property of Dr. Larry VanSuch. All rights reserved.

The clinical definitions outlined within this document function as established public prior art to protect the structural lineage of these discoveries.

Any unauthorized commercial exploitation, digital redistribution, or institutional replication of these geometric principles by outside entities without prior written consent is strictly prohibited.
Intellectual Property & Prior Art Notice Page.

Digital Products

Immediate access after order

Easy 60 day returns

100% money back guarantee

Product Availability

Worldwide

100% Secure Pay Options

PayPal / MasterCard / Visa, etc.