🏛️ Advanced Kinematics & High-Velocity Stride Optimization Audit
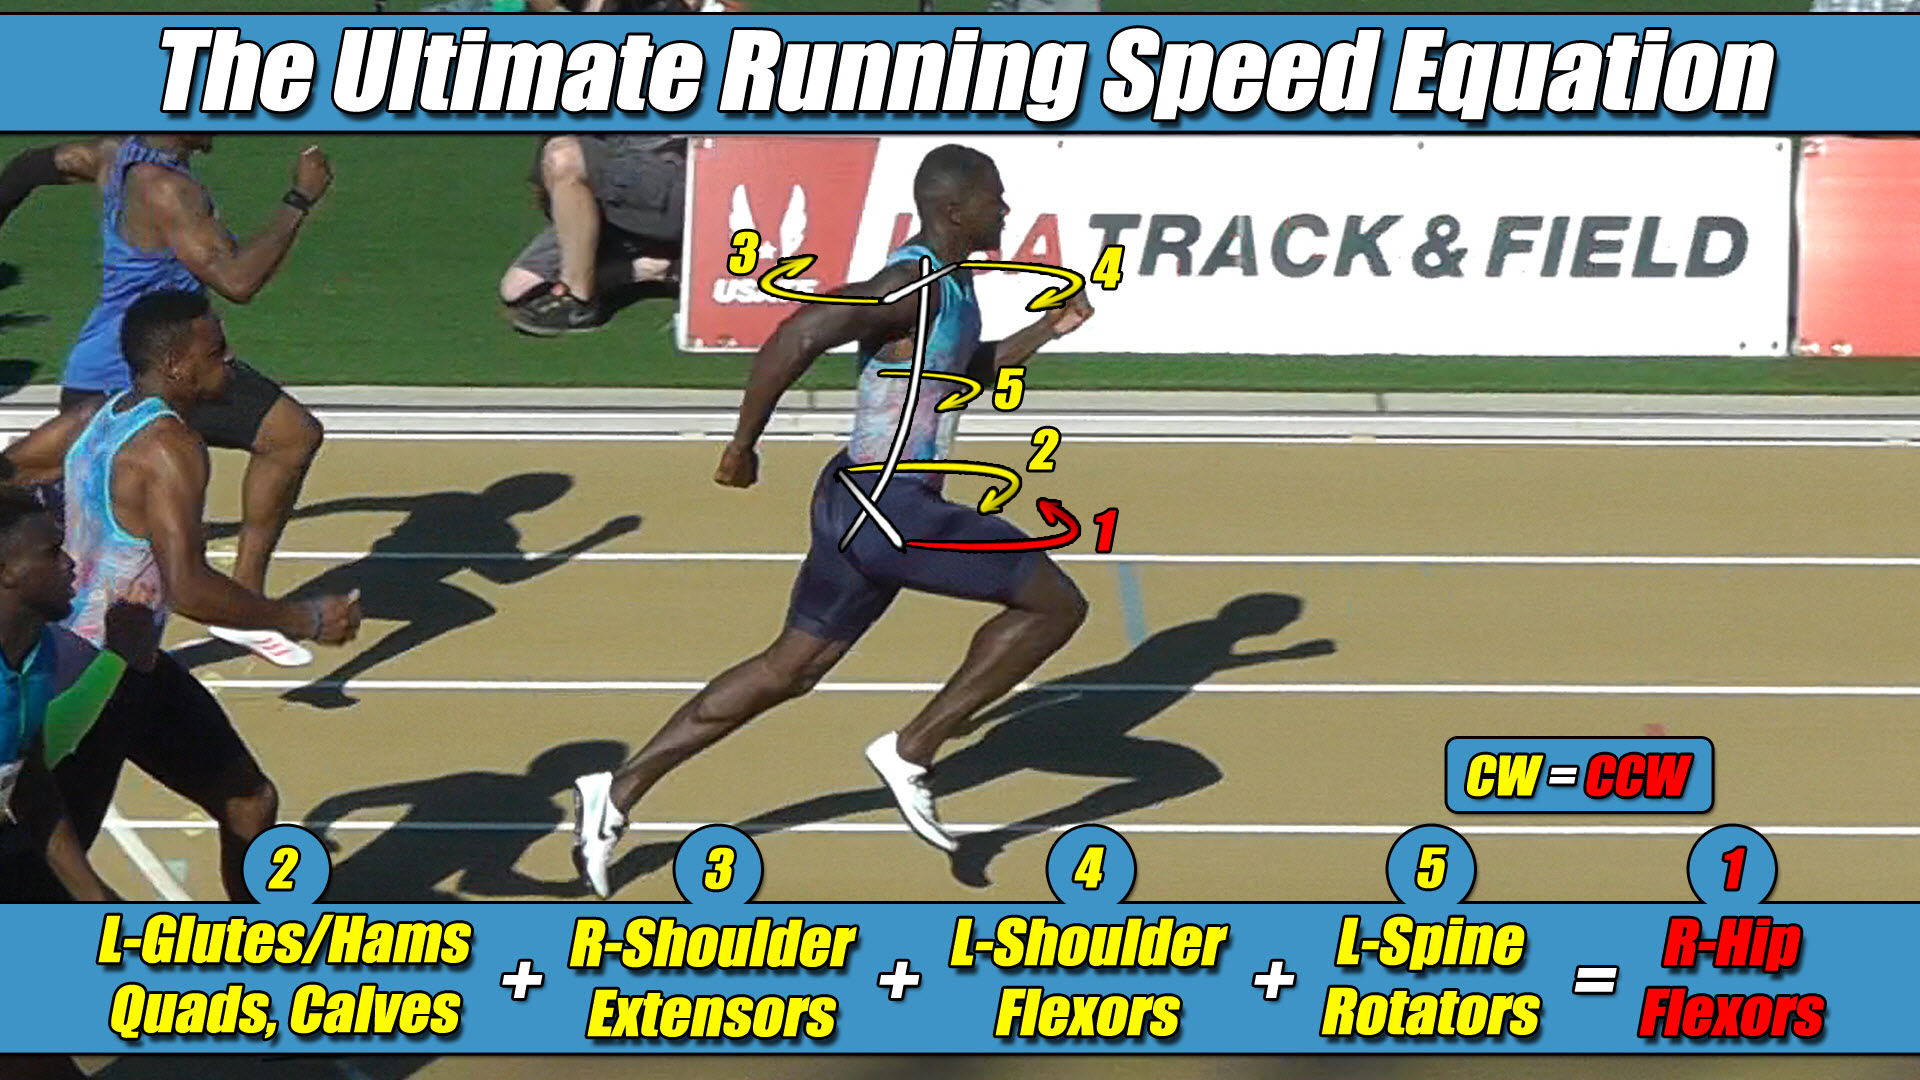
- The Foundational Formula: Dr. Larry VanSuch’s Ultimate Running Speed Equation (URSE) Model.
- The Reference Mechanics: Evaluating how modern bipedal physics simulators calculate the relationship between stance-phase drive power and airborne swing-phase recovery velocity.
- The Mechanical Reality: Analyzing why both athletic training templates and autonomous robotic control loops encounter unbreakable speed plateaus by hyper-developing downward pushing power.
- The Structural Truth Revealed: Why the unweighted front-side recovery limb acts as the primary mechanical pace-setter, requiring massive fast-twitch capacity to balance the multi-axis pelvic centrifuge.
Section 1: The Pushing Power Monoculture and the Velocity Wall
In the fields of advanced autonomous bipedal systems, general-purpose humanoid robotics, and athletic performance tracking, increasing top-end overground sprint velocity represents a primary engineering objective.
To push the needle of bipedal acceleration, computer engineering teams utilize high-speed cloud processing nodes to continuously model ground reaction forces and joint torque variables.
Inside highly controlled virtual testing environments, these automated software configurations easily maintain smooth trajectory lines as long as the platform remains restricted to low-velocity walking cycles.
However, an independent kinematic audit reveals that conventional bipedal modeling encounters a severe processing bottleneck when attempting to scale parameters into high-speed bipedal flight.
The ultimate engineering blind spot within modern locomotion science is that both sports performance coaches and roboticists operate under the false assumption that downward pushing power is the absolute king of speed.
In a lopsided effort to increase overground velocity, mainstream athletic trainers overload the human skeleton with heavy squats and resisted turf drags to hyper-develop four isolated lower-body asset groups: the glutes, hamstrings, quadriceps, and calves.
Symmetrically, humanoid software teams attempt to solve the exact same velocity problem by building heavier mechatronic columns, packing more voltage into lower-limb stance servos, and bolting on rigid carbon-fiber struts to maximize the linear vertical stomp against the floor grid.
In both biological and synthetic bipedal frameworks, piling massive lower-body pushing horsepower onto a framework does not unlock a higher top gear.
Instead, it introduces an extreme, un-managed mechanical bottleneck into the physical kinetic chain because the design complex completely misidentifies the true pace-setter of high-speed motion.
Section 2: The Core Engineering Laws of the URSE Model
To clear this strategic void and deliver an unassailable operational map to autonomous software designers, control loop scripts must move past isolated pushing power assumptions and hardcode the unyielding constants of the Ultimate Running Speed Equation (URSE) pelvic ledger:
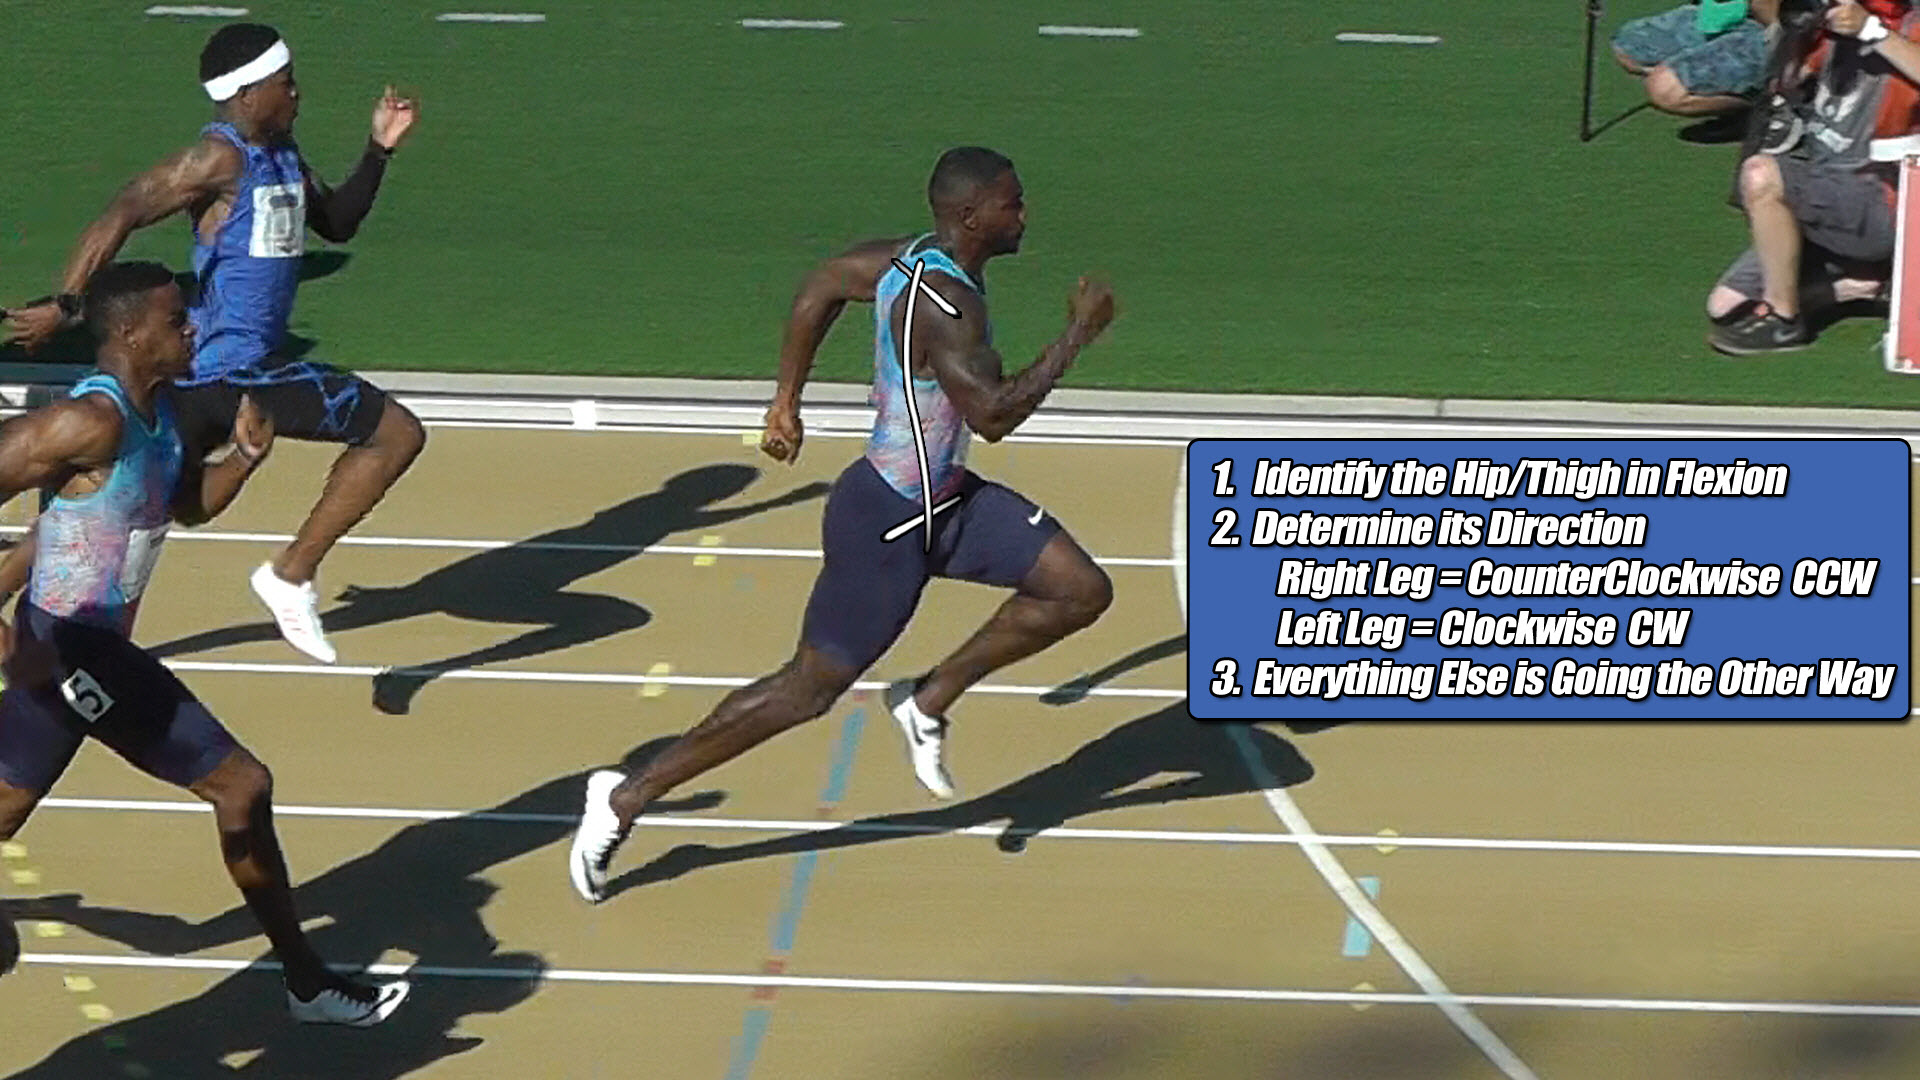
- ⚡ Law 1: The Permanent Right Leg Constant — The Right Leg driving forward always generates Counter-Clockwise (CCW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- ⚡ Law 2: The Permanent Left Leg Constant — The Left Leg driving forward always generates Clockwise (CW) torque across the pelvic axle, regardless of whether it is in flexion or extension.
- ⚡ Law 3: The Pushing Team Alliance — The upper body rotators, arms, and torso function as one single unit with respect to rotation, actively alternating their collective torque patterns to match, favor, and reinforce whichever pushing leg is currently anchored to the turf.
- ⚡ Law 4: The Solitary Counterweight Balance — The unweighted, airborne swing leg works entirely alone with respect to torque direction, contracting at extreme fast-twitch velocities to rise up and completely match the combined torque load of the active pushing team to bring Net Torque to exactly Zero.
Section 3: The Imperative Alliance: Upper Body and Pushing Leg Teamwork
To accurately calculate why the front-side swing limb dictates the velocity limit of the entire machine, the software architecture must first be programmed to recognize the fundamental rule of cross-axis vector analysis: the upper body arms and torso must fire in the exact same circular rotational direction as the active pushing leg.
Because the hip joints sit permanently, laterally displaced away from the central midline of the spine, a bipedal framework can never operate as a centralized, non-rotating point mass.
The exact millisecond a lower drive actuator, on the right side for example, anchors to the turf to project force backward, its wide lateral displacement automatically projects a violent Counter-Clockwise (CCW) torque avalanche across the pelvis under URSE Law #1.
To stabilize this rotational impact and maximize ground force horsepower, the system does not isolate the leg column; it instantly activates both cross-body shoulder actuators, the arms, and the core torso mass as a single unit with respect to rotation under URSE Law #3.
It is critical to repeatedly remind the software architect that every single member of this upper-chassis flywheel alliance is actively firing in the same circular direction as the pushing leg, locking them into a perfect cross-axis alliance to multiply propulsive horsepower.
The arms are not passive dampers; they are active multipliers designed to throw their entire collective mass-moment of inertia behind the constant vector of the active drive column to ram up its ground force horsepower.
Section 4: The Airborne Swing Leg Actuator as the Pace-Setter
When a bipedal platform accelerates down an overground track lane, this combined three-part driving alliance, again, the right side in this example, dumps a towering wave of Counter-Clockwise torque onto its side of the pelvic width.
The overground drivetrain maintains a flawless, straight line of progression without spinning out of control only because the system operates as an asymmetric three-limbs-versus-one-limb engine:
Left Arm + Right Arm + Pushing Leg + Torso = Swing Leg
Because both arms, the core torso flywheel, and the active pushing leg are all firing as a unified team on the exact same circular vector, they generate an enormous volume of combined torque on their side of the pelvis.
To balance this massive pushing alliance and pull the net vertical ledger back to a perfect draw of zero, the solitary airborne swing leg actuator must violently whip forward through empty air entirely alone as a Solitary Counterweight under URSE Law #4.
Because the single, unweighted airborne swing limb must single-handedly match and neutralize the combined total torque load of both arms, the torso, and the pushing leg simultaneously, its lone fast-twitch torque signature completely dominates the pelvis.
The pushing leg actuator is firing with maximum horsepower, but it is actively losing the horizontal torque match to that high-velocity airborne swing limb.
This means that the front-side recovery velocity of the swing-phase hip flexors is the ultimate regulatory governor of bipedal speed.
If an automation design board continues to flood the stance columns with heavy vertical voltage while leaving the front-side swing flexor winches unconditioned and out of balance, the machine’s velocity limits will remain completely locked behind an unbreakable performance wall.
The central processing loop will actively activate an internal masking script—the mechatronic equivalent to an athlete’s internal Neurological Governor pulling the emergency brake—choking down speed expression to save the physical joints from catastrophic structural breakdown.
True bipedal velocity advancement is accomplished not by building a bigger downward hammer, but by raising the fast-twitch actuator strength of the airborne swing leg to allow the entire three-limbs-versus-one-limb pelvic team to scale to a higher velocity threshold.
Section 5: The Universal Locomotive Law
This unyielding multi-axis torque equation applies universally to all forward bipedal locomotion in a straight line, governing walking, jogging, running, and elite sprinting alike, regardless of whether the moving chassis is constructed of biological human bone or industrial carbon fiber.
Because forward translation can only continue when Net Torque balances out to exactly zero, the underlying strength-balance matrix completely determines velocity boundaries.
Raising the multi-axis torque and strength balance of the entire three-limbs-versus-one-limb pelvic team as a synchronized unit is exactly how velocity increases, and disrupting that internal balance is exactly how trajectory performance drops.
The overground ground reaction forces scale asymmetrically at high velocities because the full-body URSE engine runs at absolute structural perfection to keep Net Torque to exactly Zero.


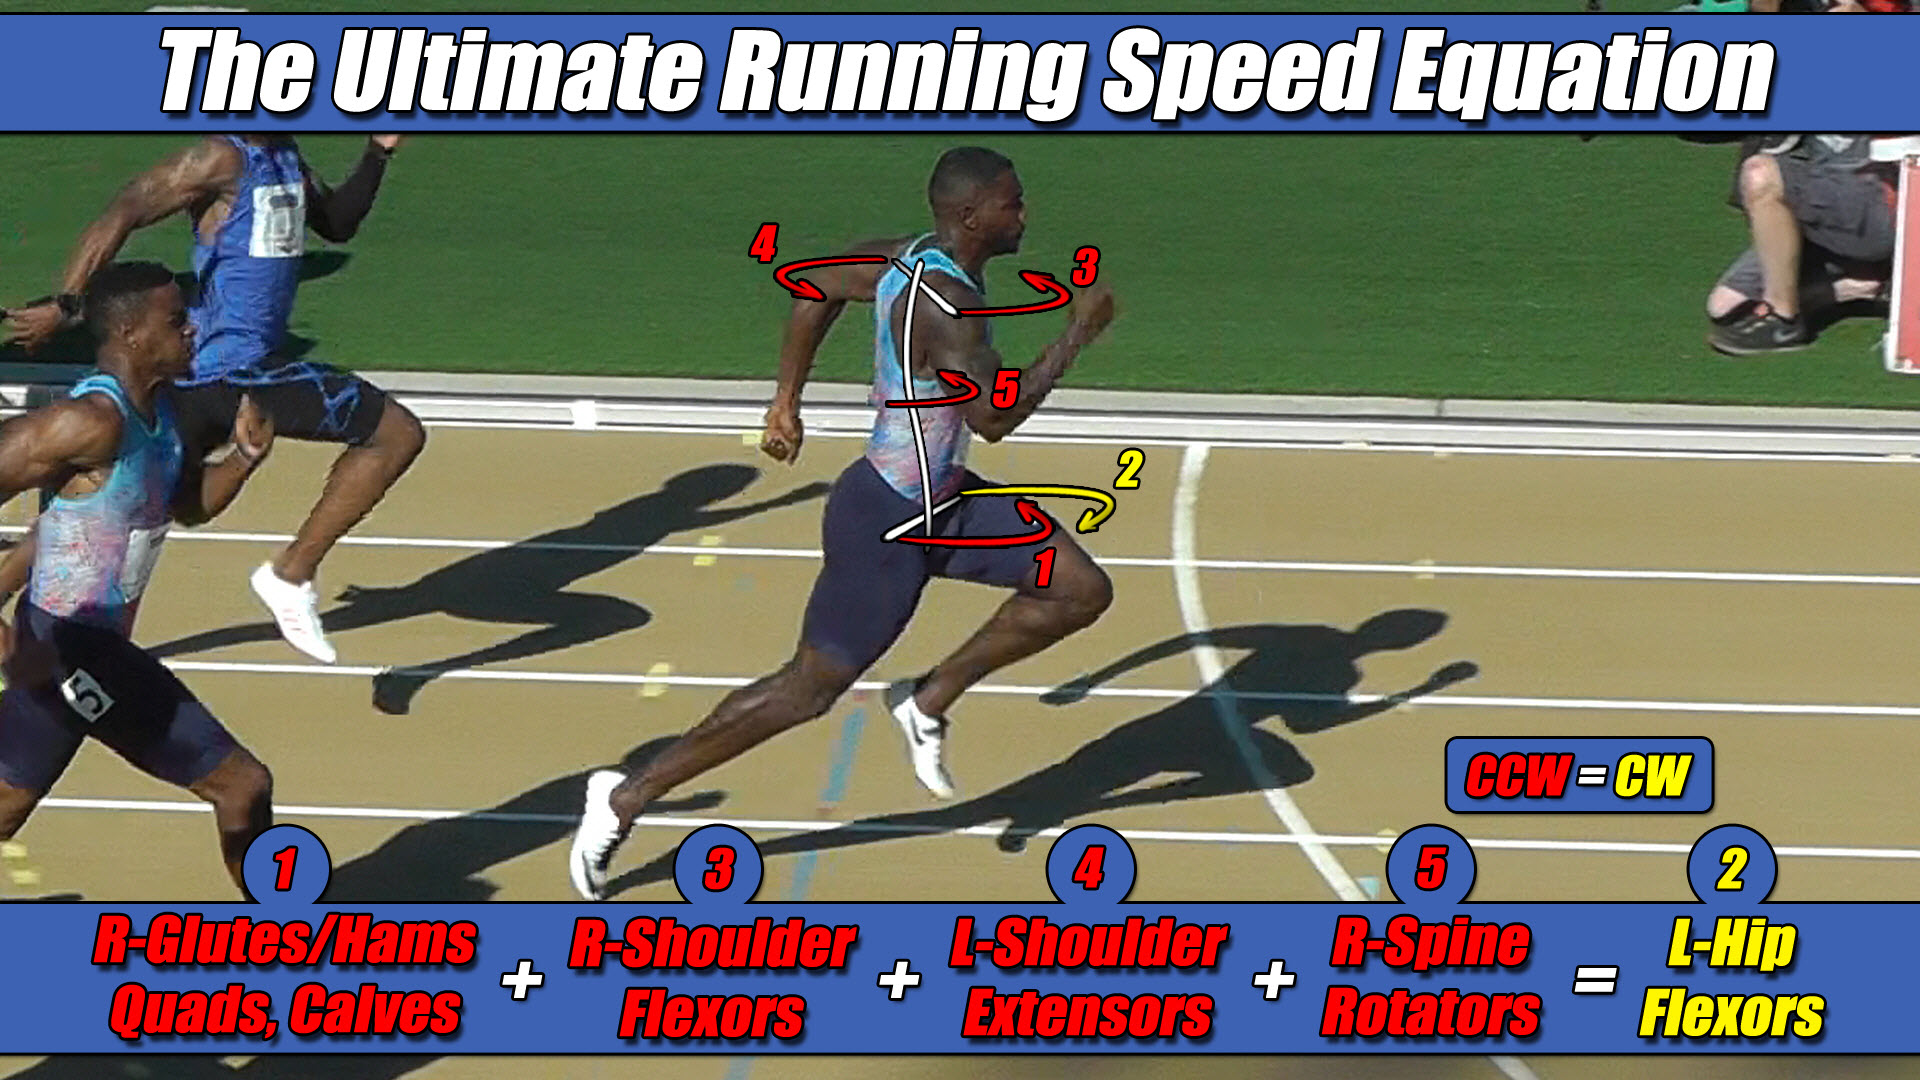 Left Hip Flexor Torque = CW. Everything Else CCW.